 Djinious




AC grid stability
Does the grid survive the fault? Synchronous machines whose rotor angles must stay in step, a three-phase short circuit, and the critical clearing time that separates a recoverable swing from a blackout — the swing equation, the equal-area criterion, multi-machine stability, and the low-inertia renewables concern.
 DjiniousLab
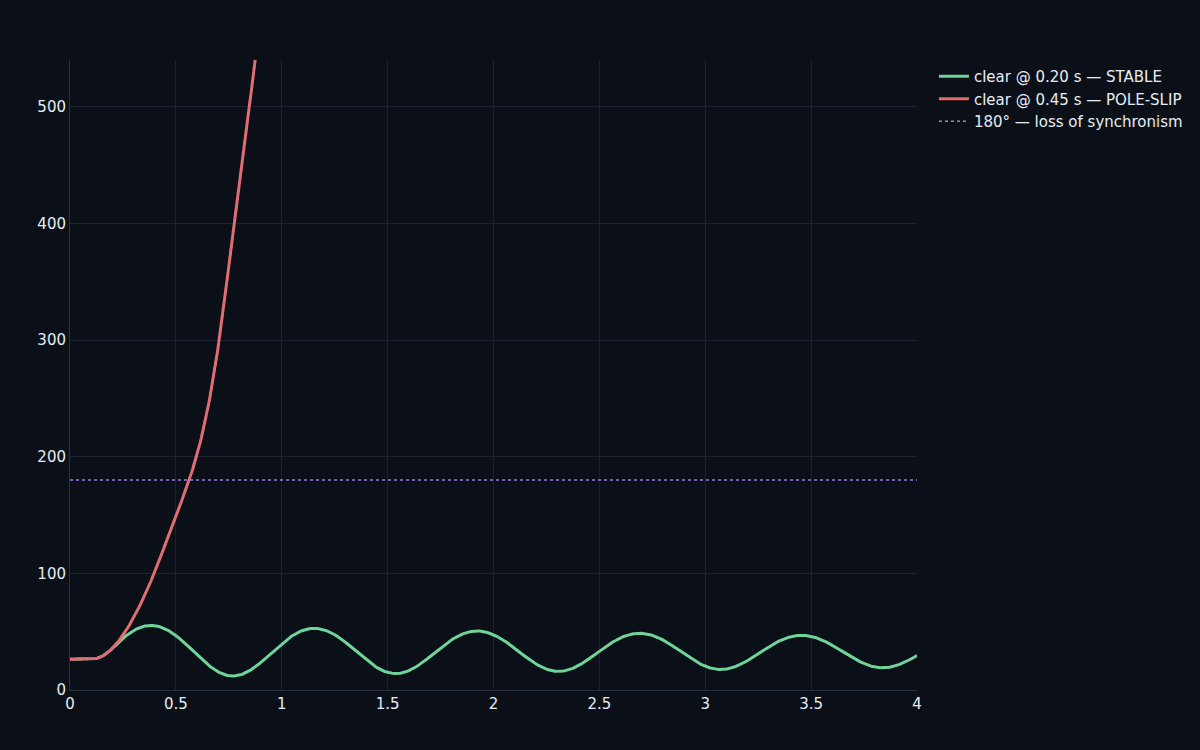
- critical clearing time (SMIB)
- 0.37 scritical clearing time (SMIB)
- equal-area vs time-domain agreement
- 1.9%equal-area vs time-domain agreement
- settling with a stabilizer
- 20 → 5.2 ssettling with a stabilizer
- RoCoF when inertia halves
- 2×RoCoF when inertia halves
- design notebooks
- 10design notebooks
- requirements PASS
- 5 / 5requirements PASS
Clear the fault in time and the grid holds. Too late, and it falls.
An AC power grid runs on synchronous machines spinning in lockstep. When a short circuit hits, each generator's rotor swings — and the question that keeps the lights on is whether they swing and re-settle, or whether one accelerates past the point of no return, slips out of step, and triggers a cascade. The margin is measured in tens of milliseconds: the critical clearing time. This program models that swing from the single-machine textbook case up to a multi-machine grid, the way PSS®E and PSCAD do — and ends on the inertia question the renewables transition is forcing.
A generator is a mass on a spring made of electricity.
The swing equation governs a synchronous machine's rotor angle: mechanical power in, electrical power out, and an inertia that resists change. The electrical power transferred across the network follows P = Pmax·sin δ — a curve with a stable equilibrium where the machine normally sits and an unstable one past the peak. Push the angle beyond that peak and the restoring power falls instead of rising: the machine runs away. Everything in transient stability is about staying on the right side of that curve.
DjiniousLab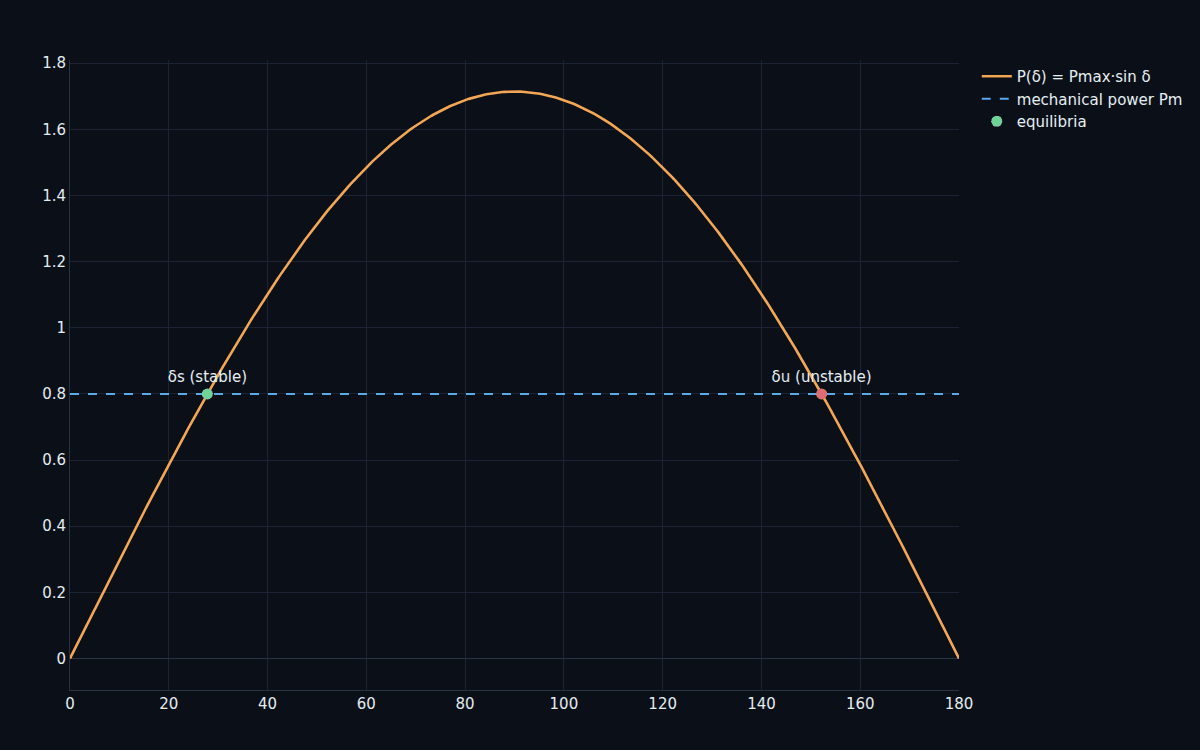 DjiniousLab
You can predict the limit without simulating it.
The equal-area criterion turns the stability question into geometry: during the fault the machine accelerates, accumulating an area under the power-angle curve; after clearing it must give that energy back as an equal decelerating area before the angle reaches the point of no return. Set the two areas equal and you get the critical clearing angle in closed form — and it matches the time-domain simulation to under 2%. Theory and simulation agreeing is what lets you trust the limit on a grid too large to eyeball.
DjiniousLab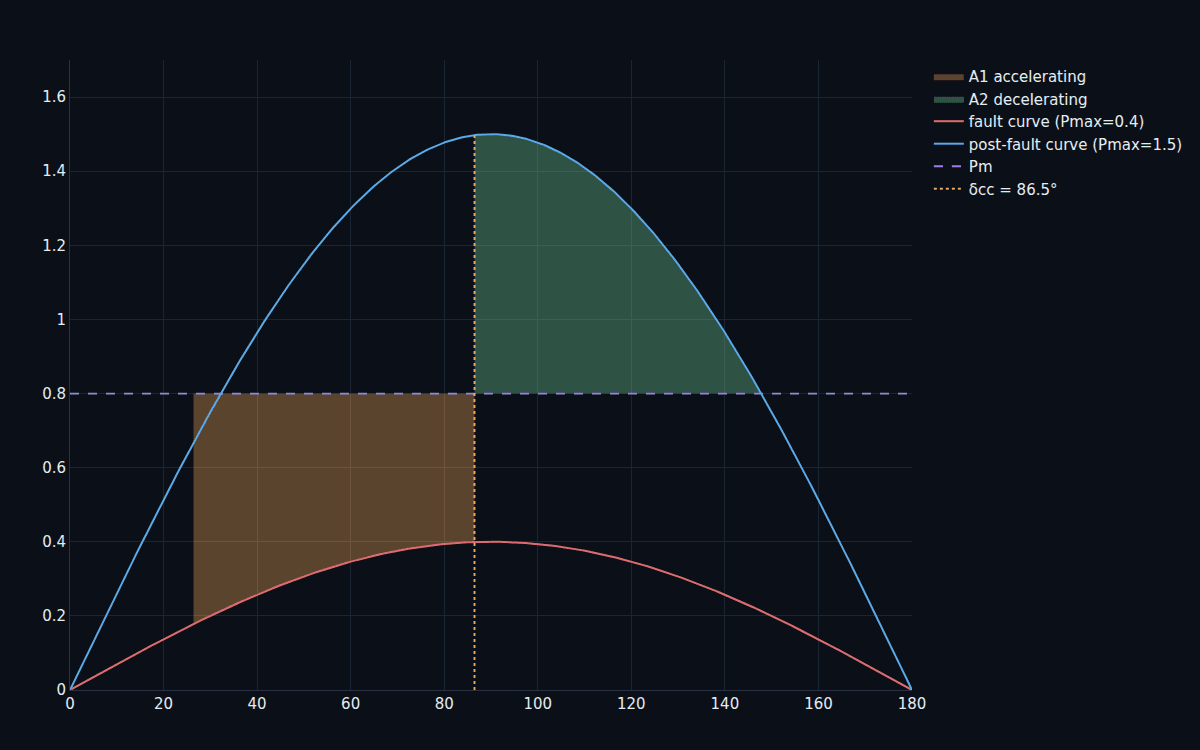
Real grids have many machines — and they argue.
One machine against an infinite bus is the textbook; a real grid is dozens of machines coupled through a network, swinging against each other. Reduce the network to the generator nodes and the same swing dynamics produce inter-area oscillations — groups of machines rocking against other groups — that must damp out after a disturbance. The program builds a multi-machine system, finds its equilibrium, faults a line, and shows the machines either staying in step or one of them losing synchronism, with its own critical clearing time.
DjiniousLab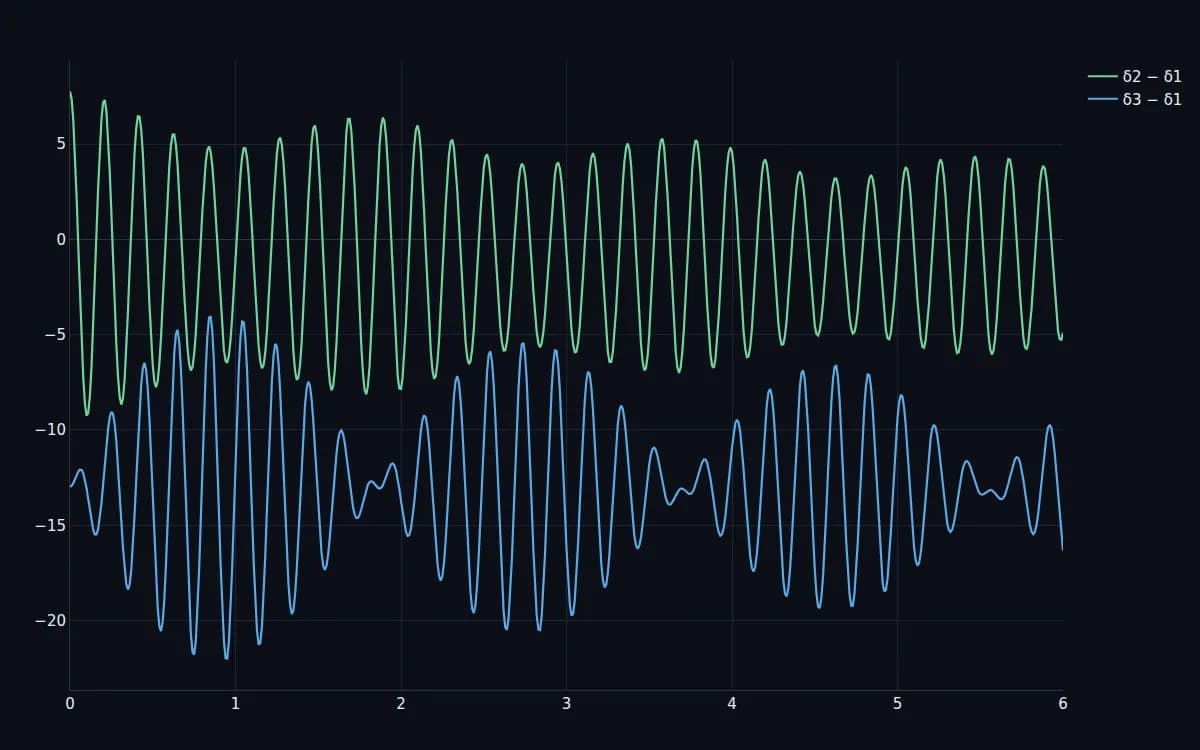
Less spinning iron means a twitchier grid.
Synchronous generators carry physical inertia — spinning mass that resists frequency change and buys time after a disturbance. Replace them with inverter-based wind and solar and that inertia falls, so the same generation-load imbalance produces a steeper rate-of-change-of-frequency and a deeper frequency nadir. The program quantifies it: halve the inertia and the RoCoF doubles. It's the stability concern the energy transition is forcing onto every grid operator, modelled directly.
DjiniousLab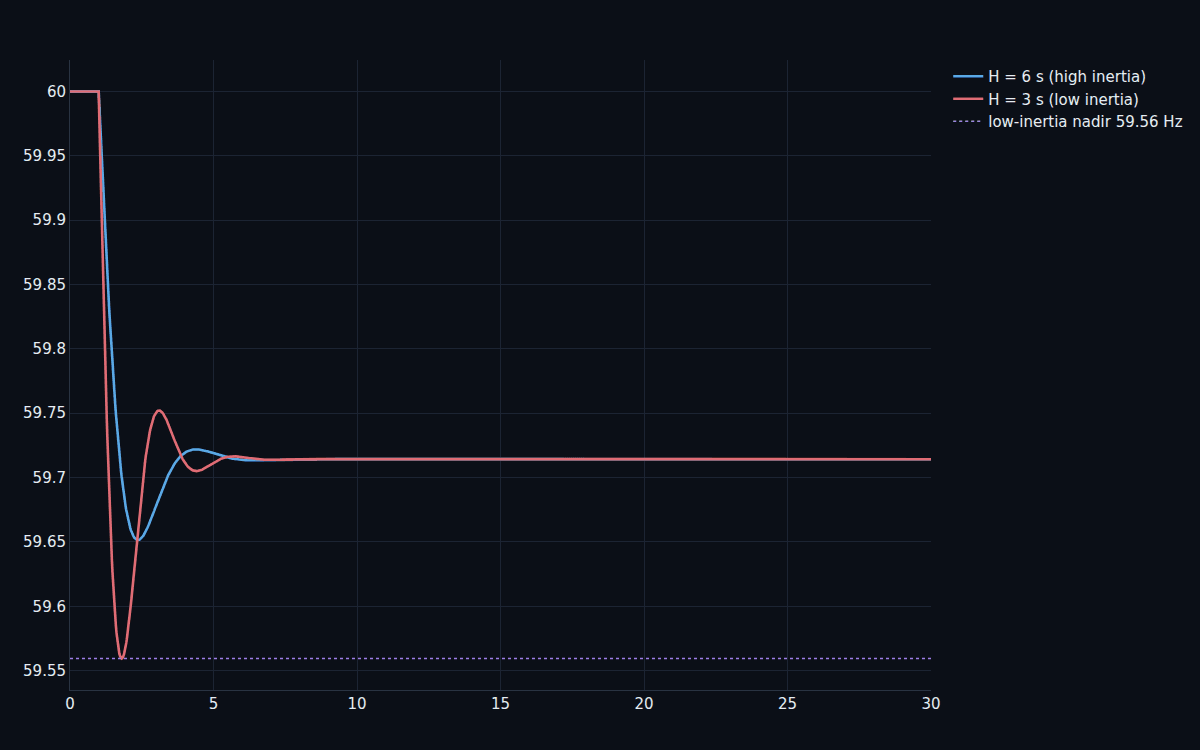
Every number re-derived at sign-off.
The V&V notebook rebuilds the machines and network from scratch and re-derives each requirement against theory, printing a PASS/FAIL board.
Result
- SMIB stable vs pole-slip: 0.97 / 330 rad
- Equal-area vs simulation: 1.9%
- Multi-machine synchronism: 40.2° spread
- PSS settling improvement: 20 → 5.2 s
- Frequency nadir / RoCoF: 59.56 Hz; ×2
Requirement
- SMIB stable vs pole-slip: R-01
- Equal-area vs simulation: R-02 < few %
- Multi-machine synchronism: R-03
- PSS settling improvement: R-04
- Frequency nadir / RoCoF: R-05
Classical machines, validated against theory.
The deliverable is ten notebooks and the dossier — the swing equations on a reduced network are a causal ODE system, not an acausal one, so there's no custom block or canvas. The machines use the classical constant-voltage-behind-reactance model (not detailed two-axis dynamics with full exciter/governor models — though the stabilizer notebook adds damping control); the network is Kron-reduced and balanced positive-sequence; there's no protection-relay modelling, and parameters are indicative. What the program proves is the core of transient stability — the swing, the critical clearing time, the equal-area criterion, multi-machine stability, and the inertia question — every number re-runnable and checked against closed-form theory where it exists. It is the AC-dynamics counterpart to the DC microgrid flagship.
Keep exploring
Related use cases
 Grid-scale energySunnyGrid80 Solar-Storage PlantAn 80 MW photovoltaic plant with a 40 MW / 80 MWh battery energy-storage system and its grid substation, modelled in ELANG as an audited reference to UL 9540A and IEC 62443 — a system-of-systems where the interfaces carry as much of the design as the boxes.
 DjiniousEngineering
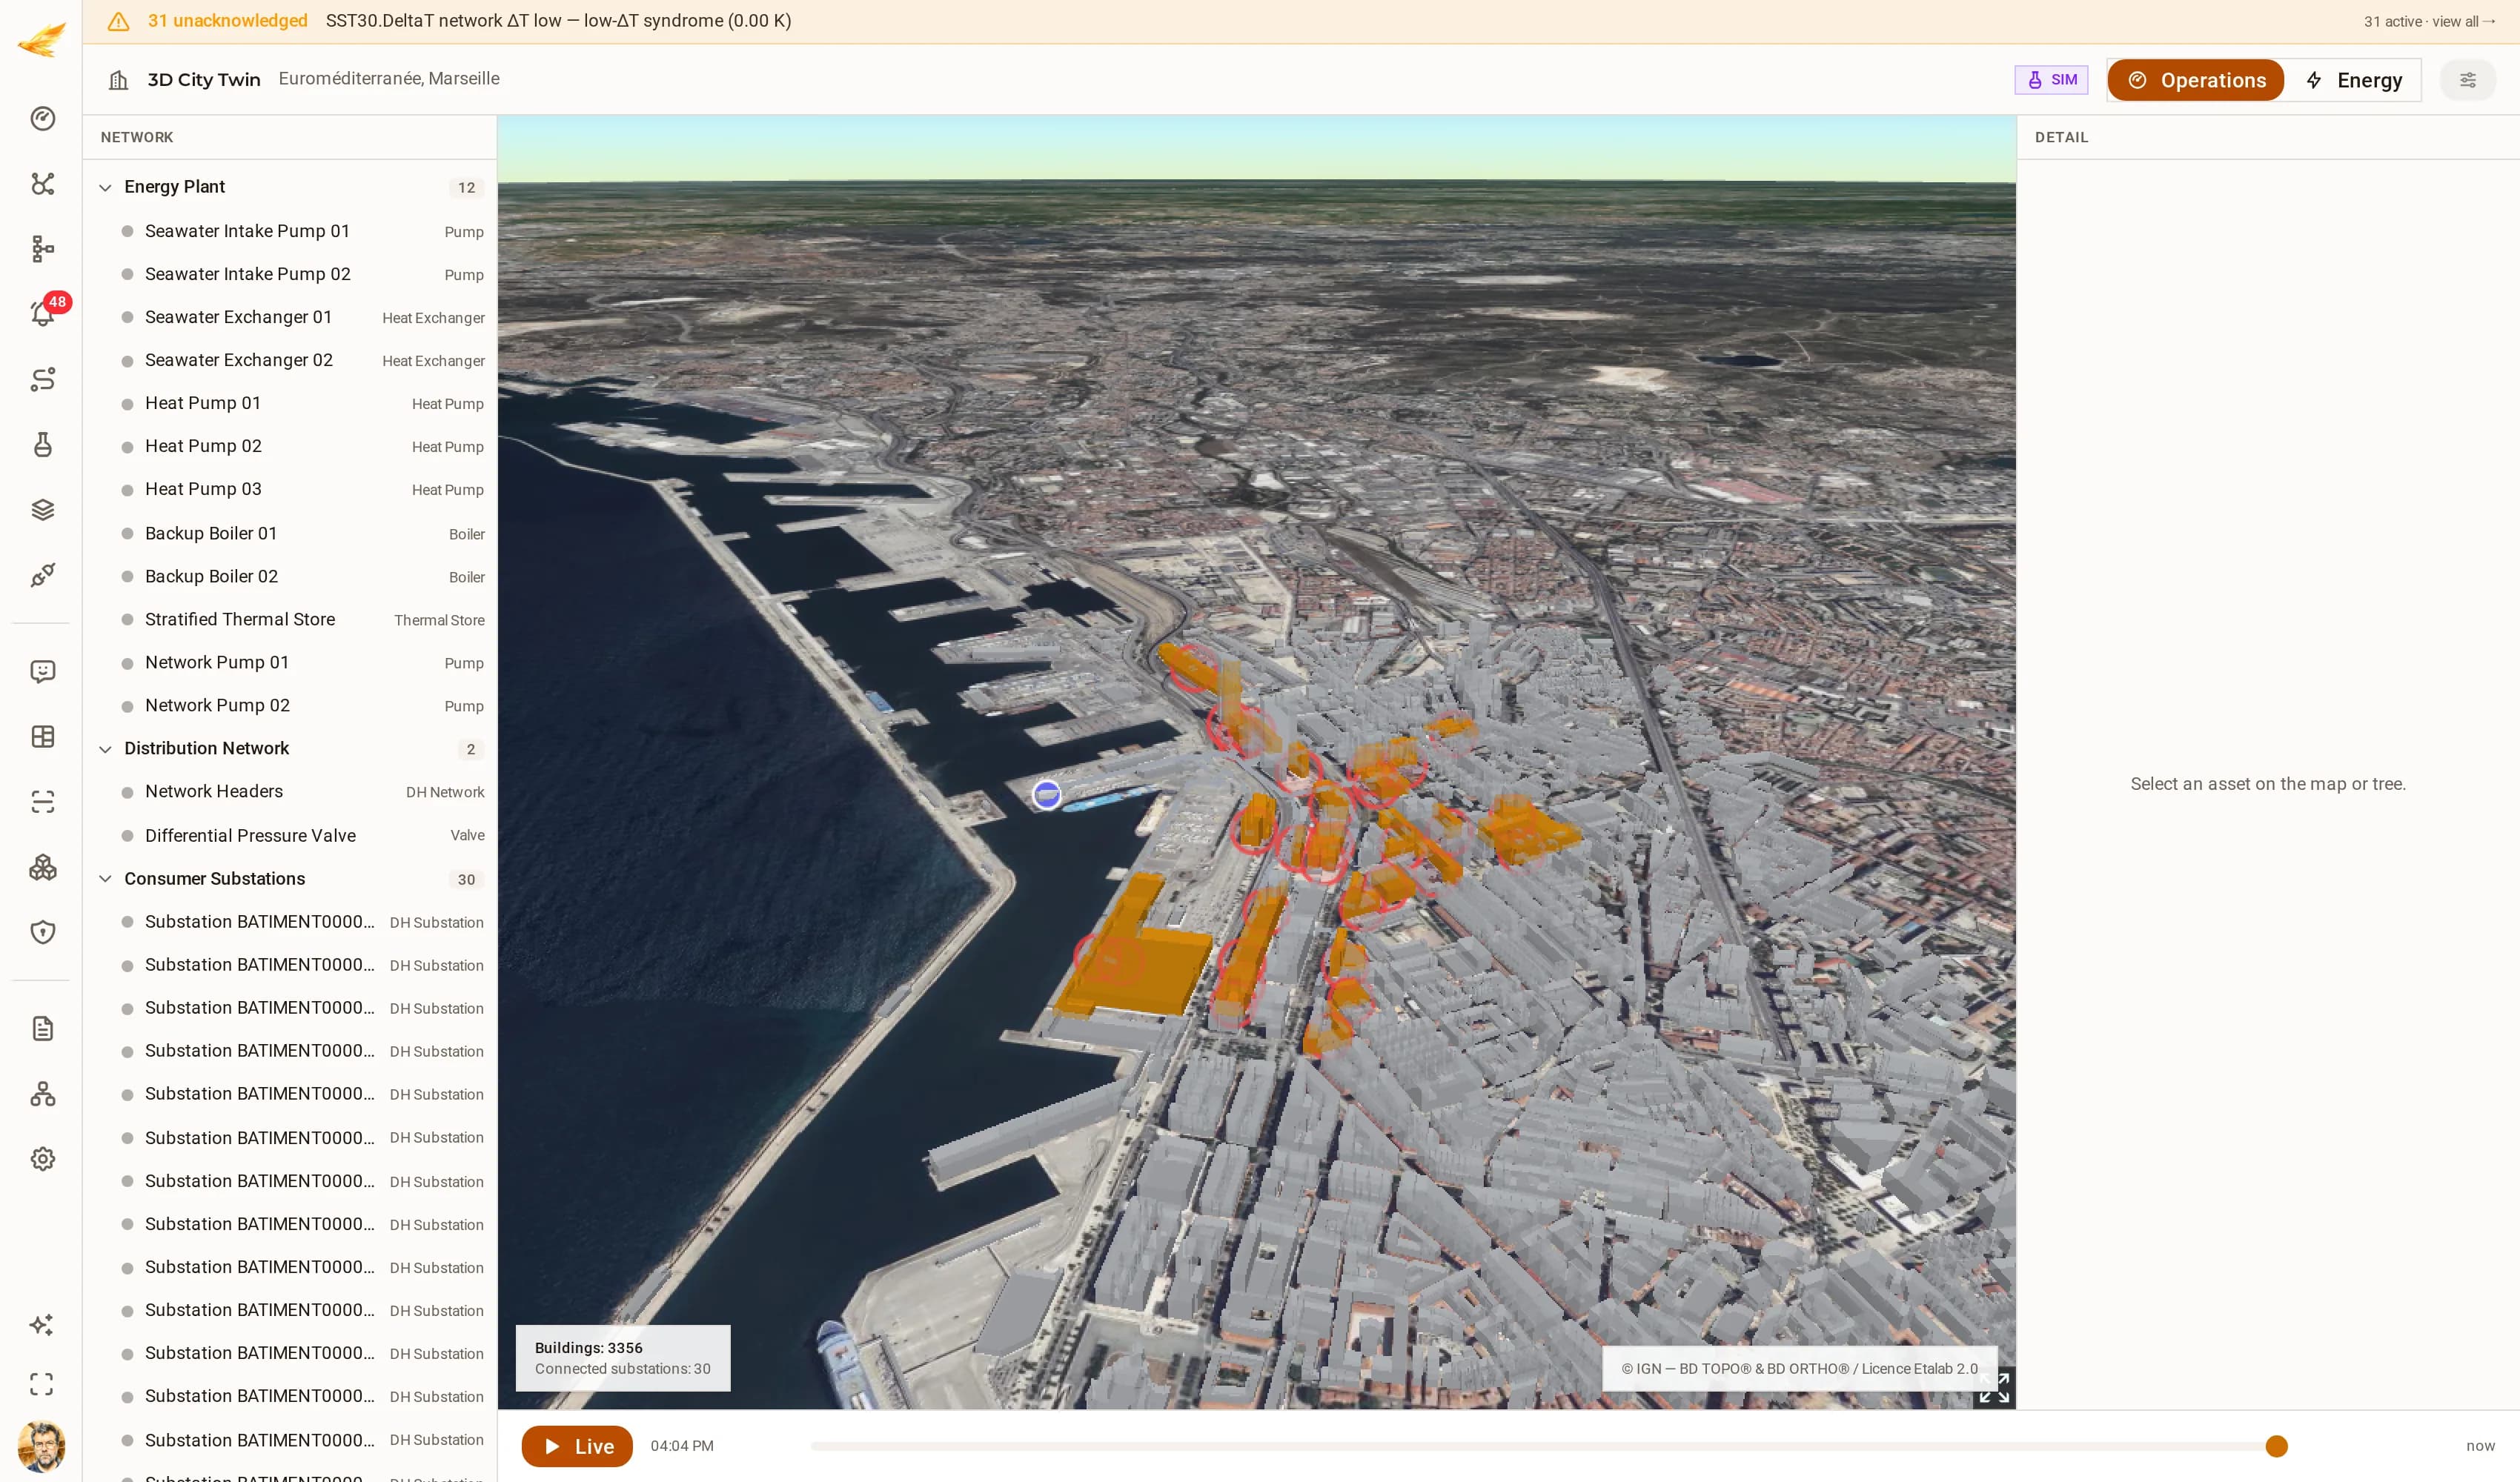 District energyEuroméditerranée District Energy NetworkA seawater-source district-heating network: two intake pumps and two seawater exchangers feeding three heat pumps, two backup boilers and a stratified thermal store, distributing through two network pumps and a differential-pressure valve to thirty consumer substations. The network is simulated; the city under it is not — every substation sits on its real IGN BD TOPO® building footprint in the Euroméditerranée quarter. It is a demonstration network on open data, not any operator's plant.
 DjiniousCC
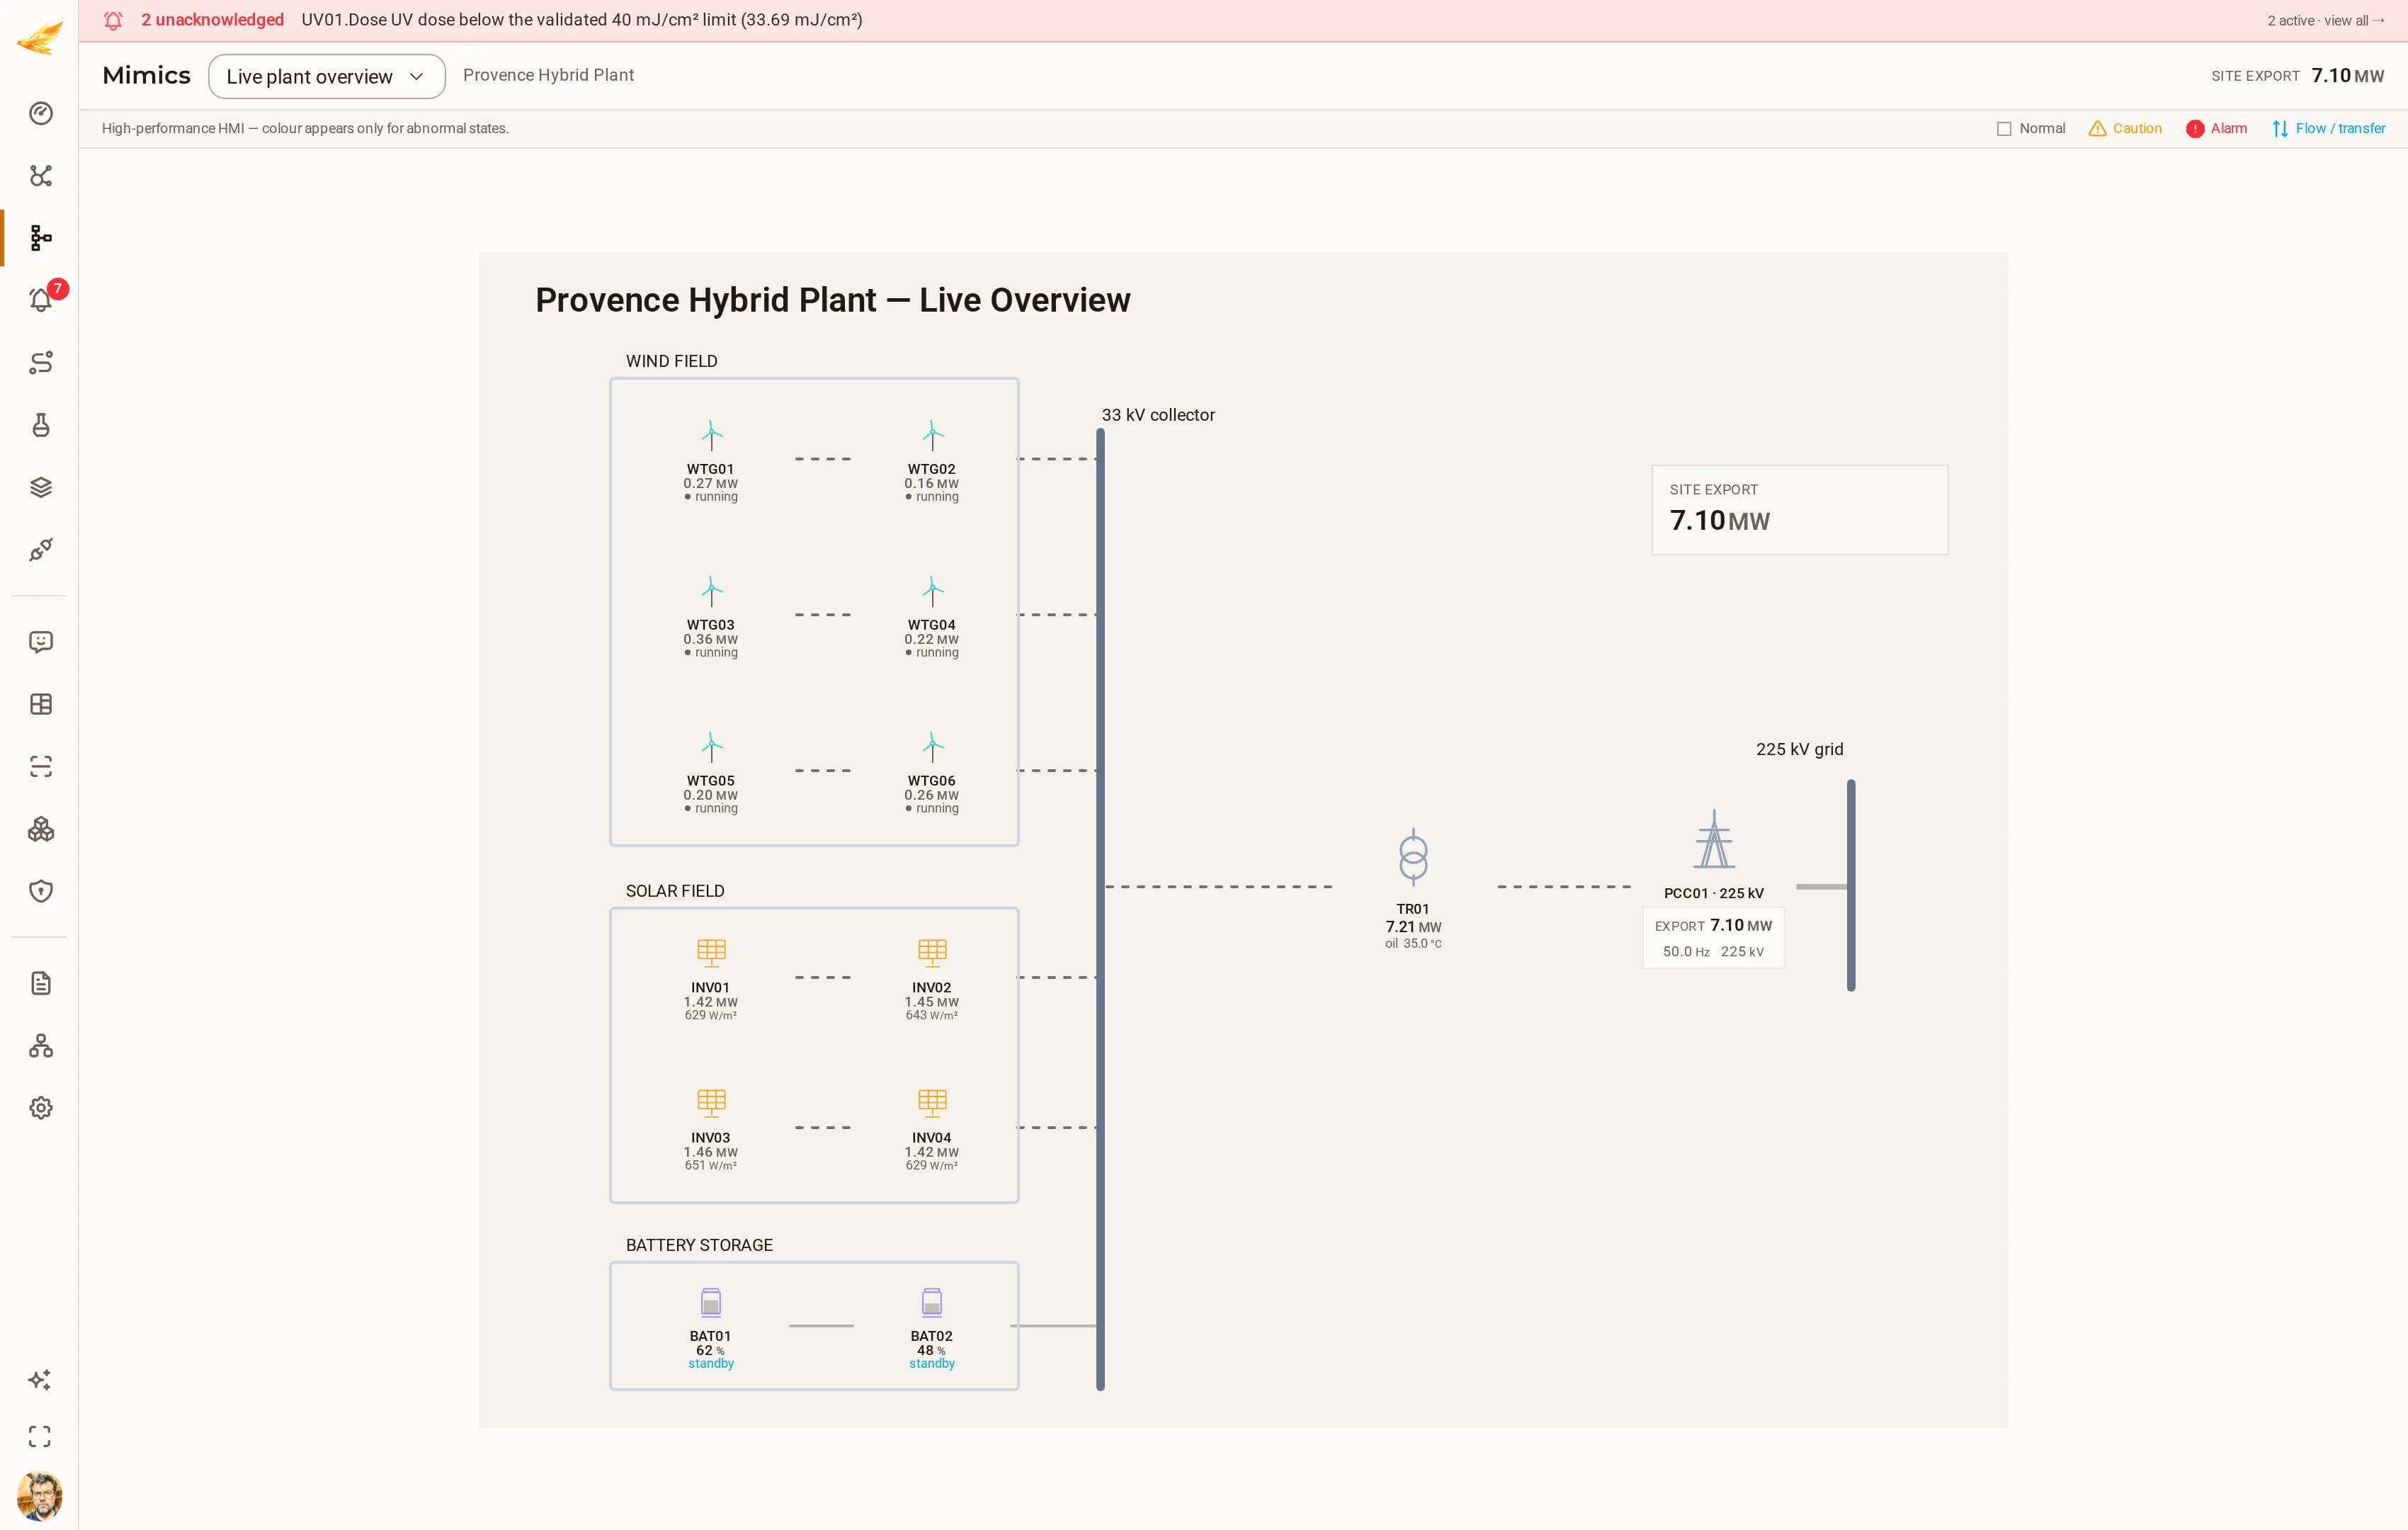 Renewable generationProvence Hybrid PlantA 120 MW hybrid plant: six wind turbines, four PV inverter blocks, two battery racks, the main 33/225 kV transformer, the grid connection point and a meteorological mast.DjiniousCC