Plan the mission. Optimise the fleet. Fly it — in simulation.
A LiDAR survey of a 500 × 500 m site near Al-Batinah South, Oman, taken from a brief to an optimal, flyable mission entirely in DjiniousLab. Drone, LiDAR and fleet specs drive a coverage plan; an optimiser tunes altitude, speed and fleet allocation to whatever you care about — fastest, fewest battery swaps, or highest resolution; a Python mission then commands a simulated UAV fleet, replayed on an animated map. Six notebooks, one workflow, all on the worker.
From a site brief to a flyable mission, in six steps.
Each step is a Python notebook running on the DjiniousLab worker — numpy/scipy for the planning maths, Plotly and Leaflet for the maps. Nothing is hard-coded: change a spec and the whole mission re-plans.
Site & datum
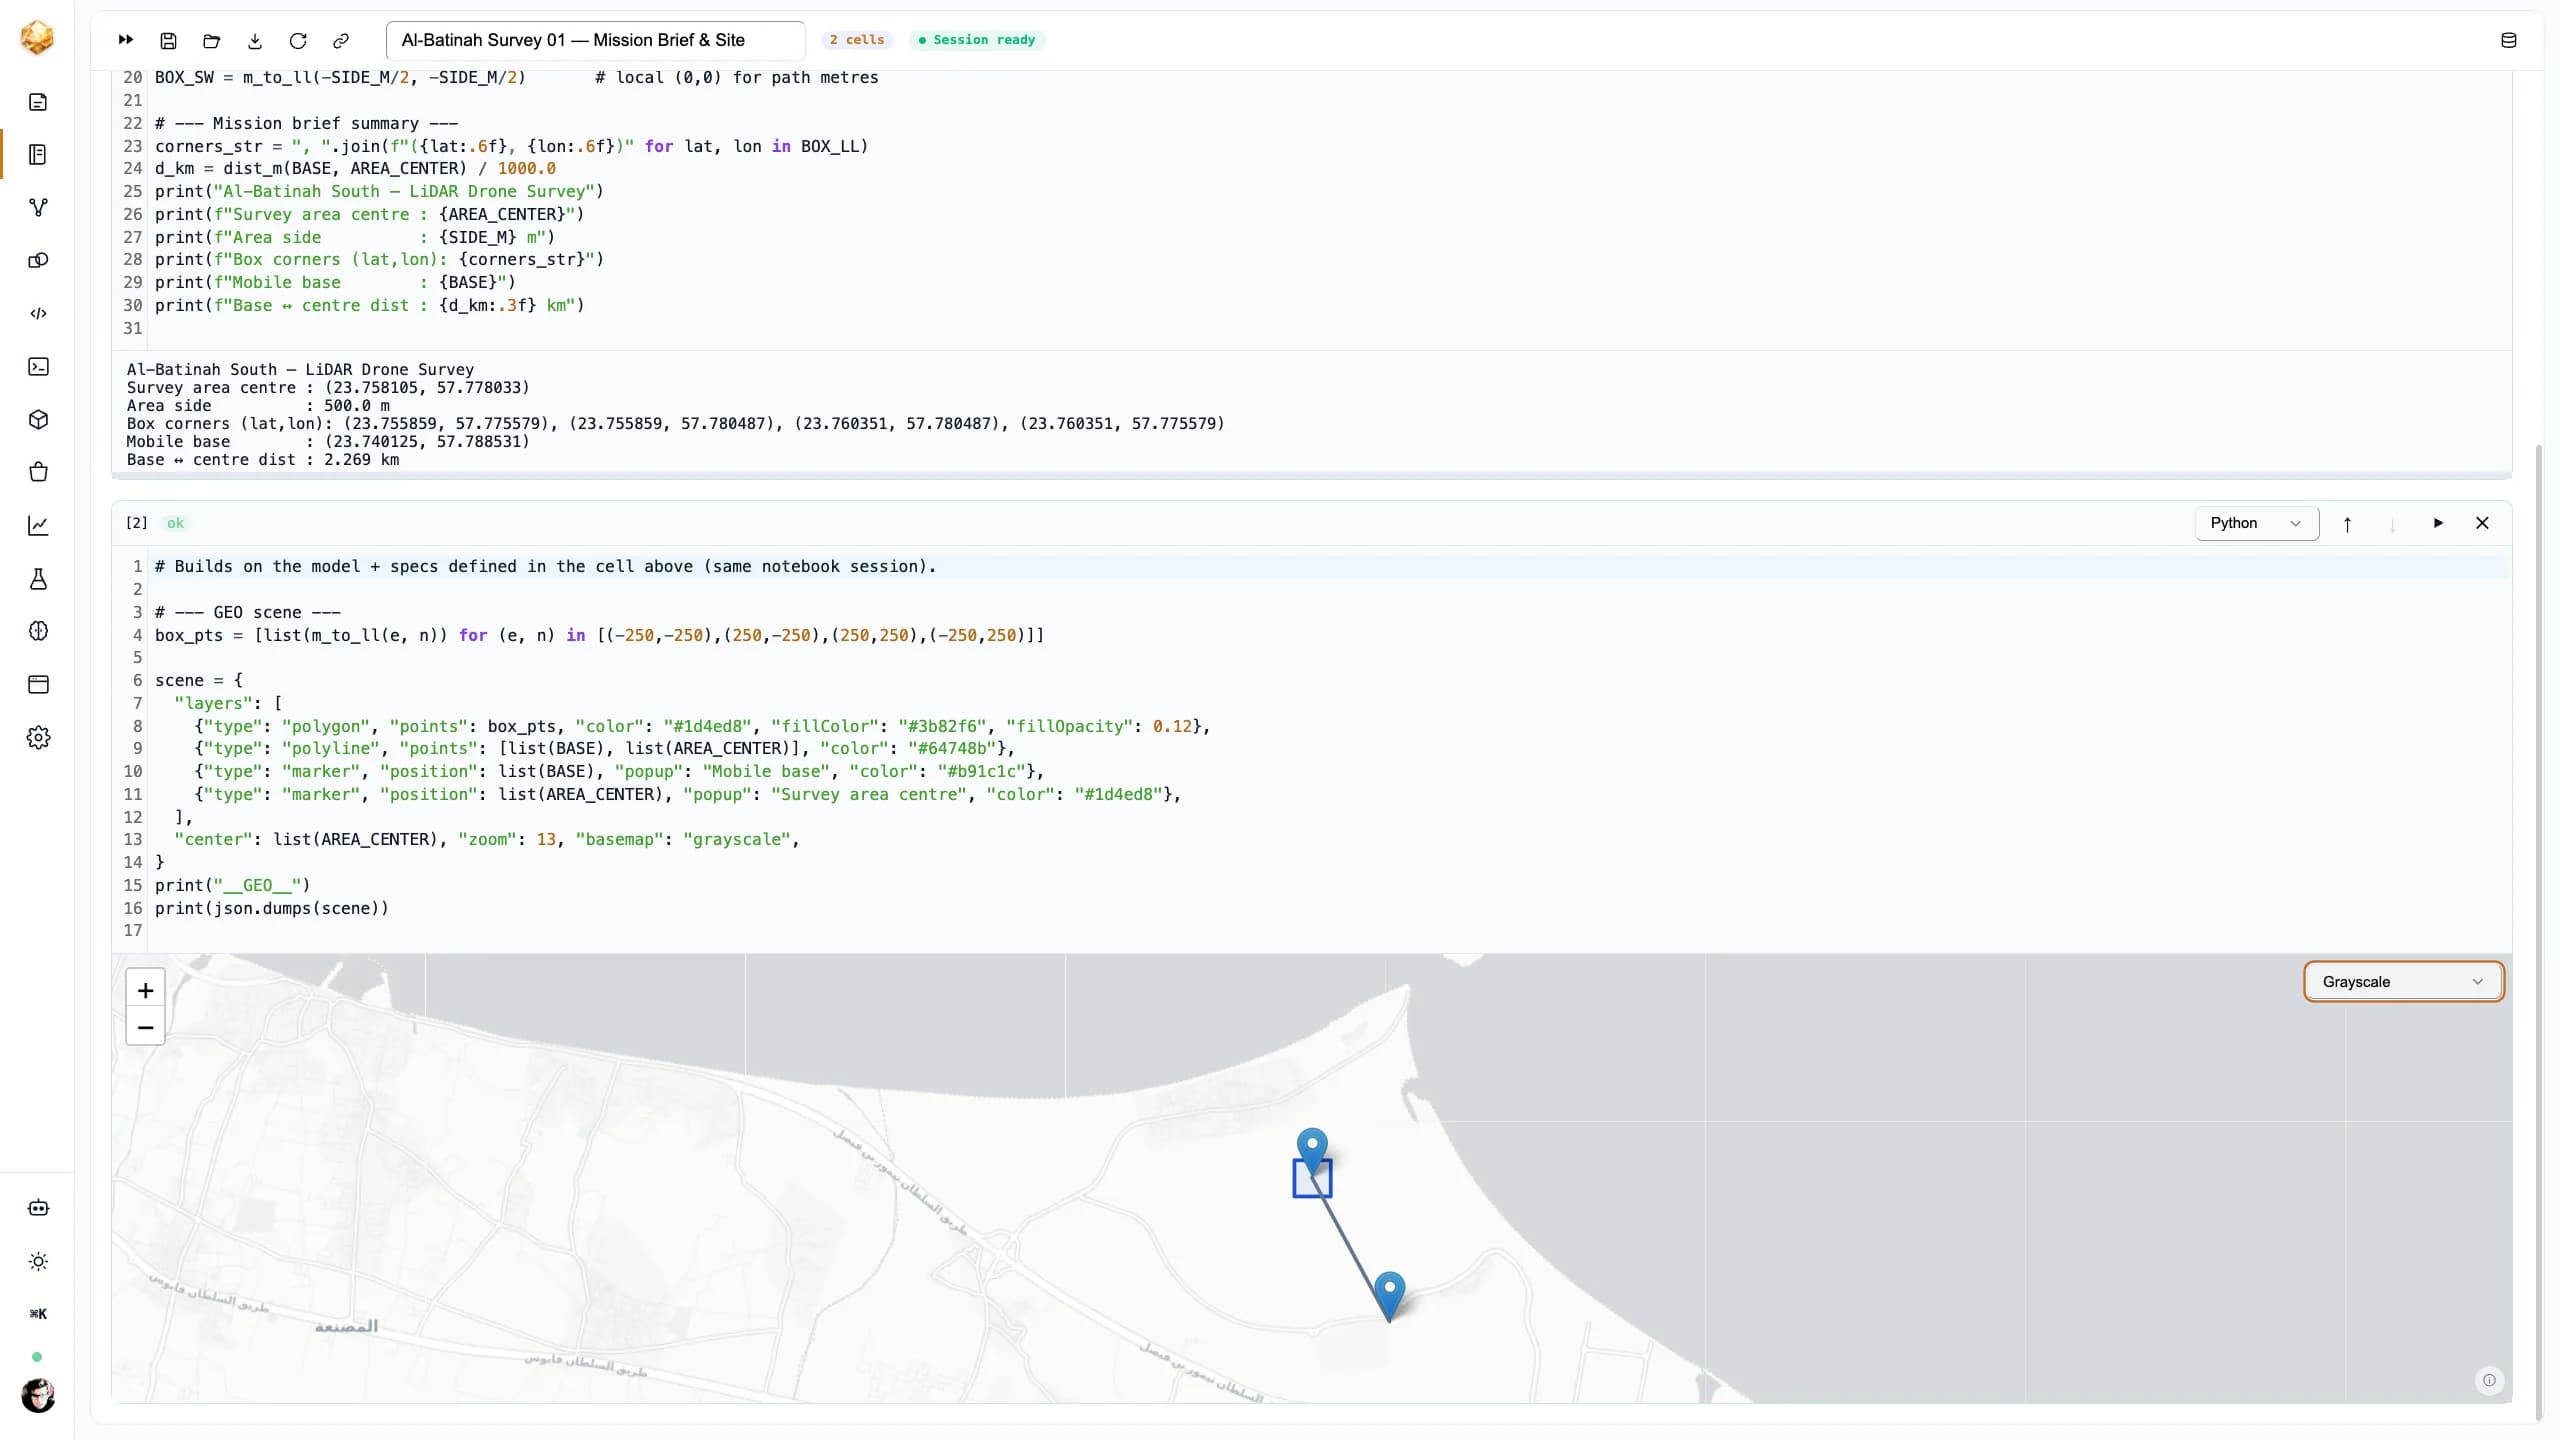
The 500 m survey box and a mobile launch base are pinned in WGS-84 over the real Al-Batinah coastline. A local east-north metre frame (equirectangular at the site latitude) carries all the geometry; base-to-area transit comes out at ~2.3 km — and it is charged against every sortie's endurance.
Drone & LiDAR spec model
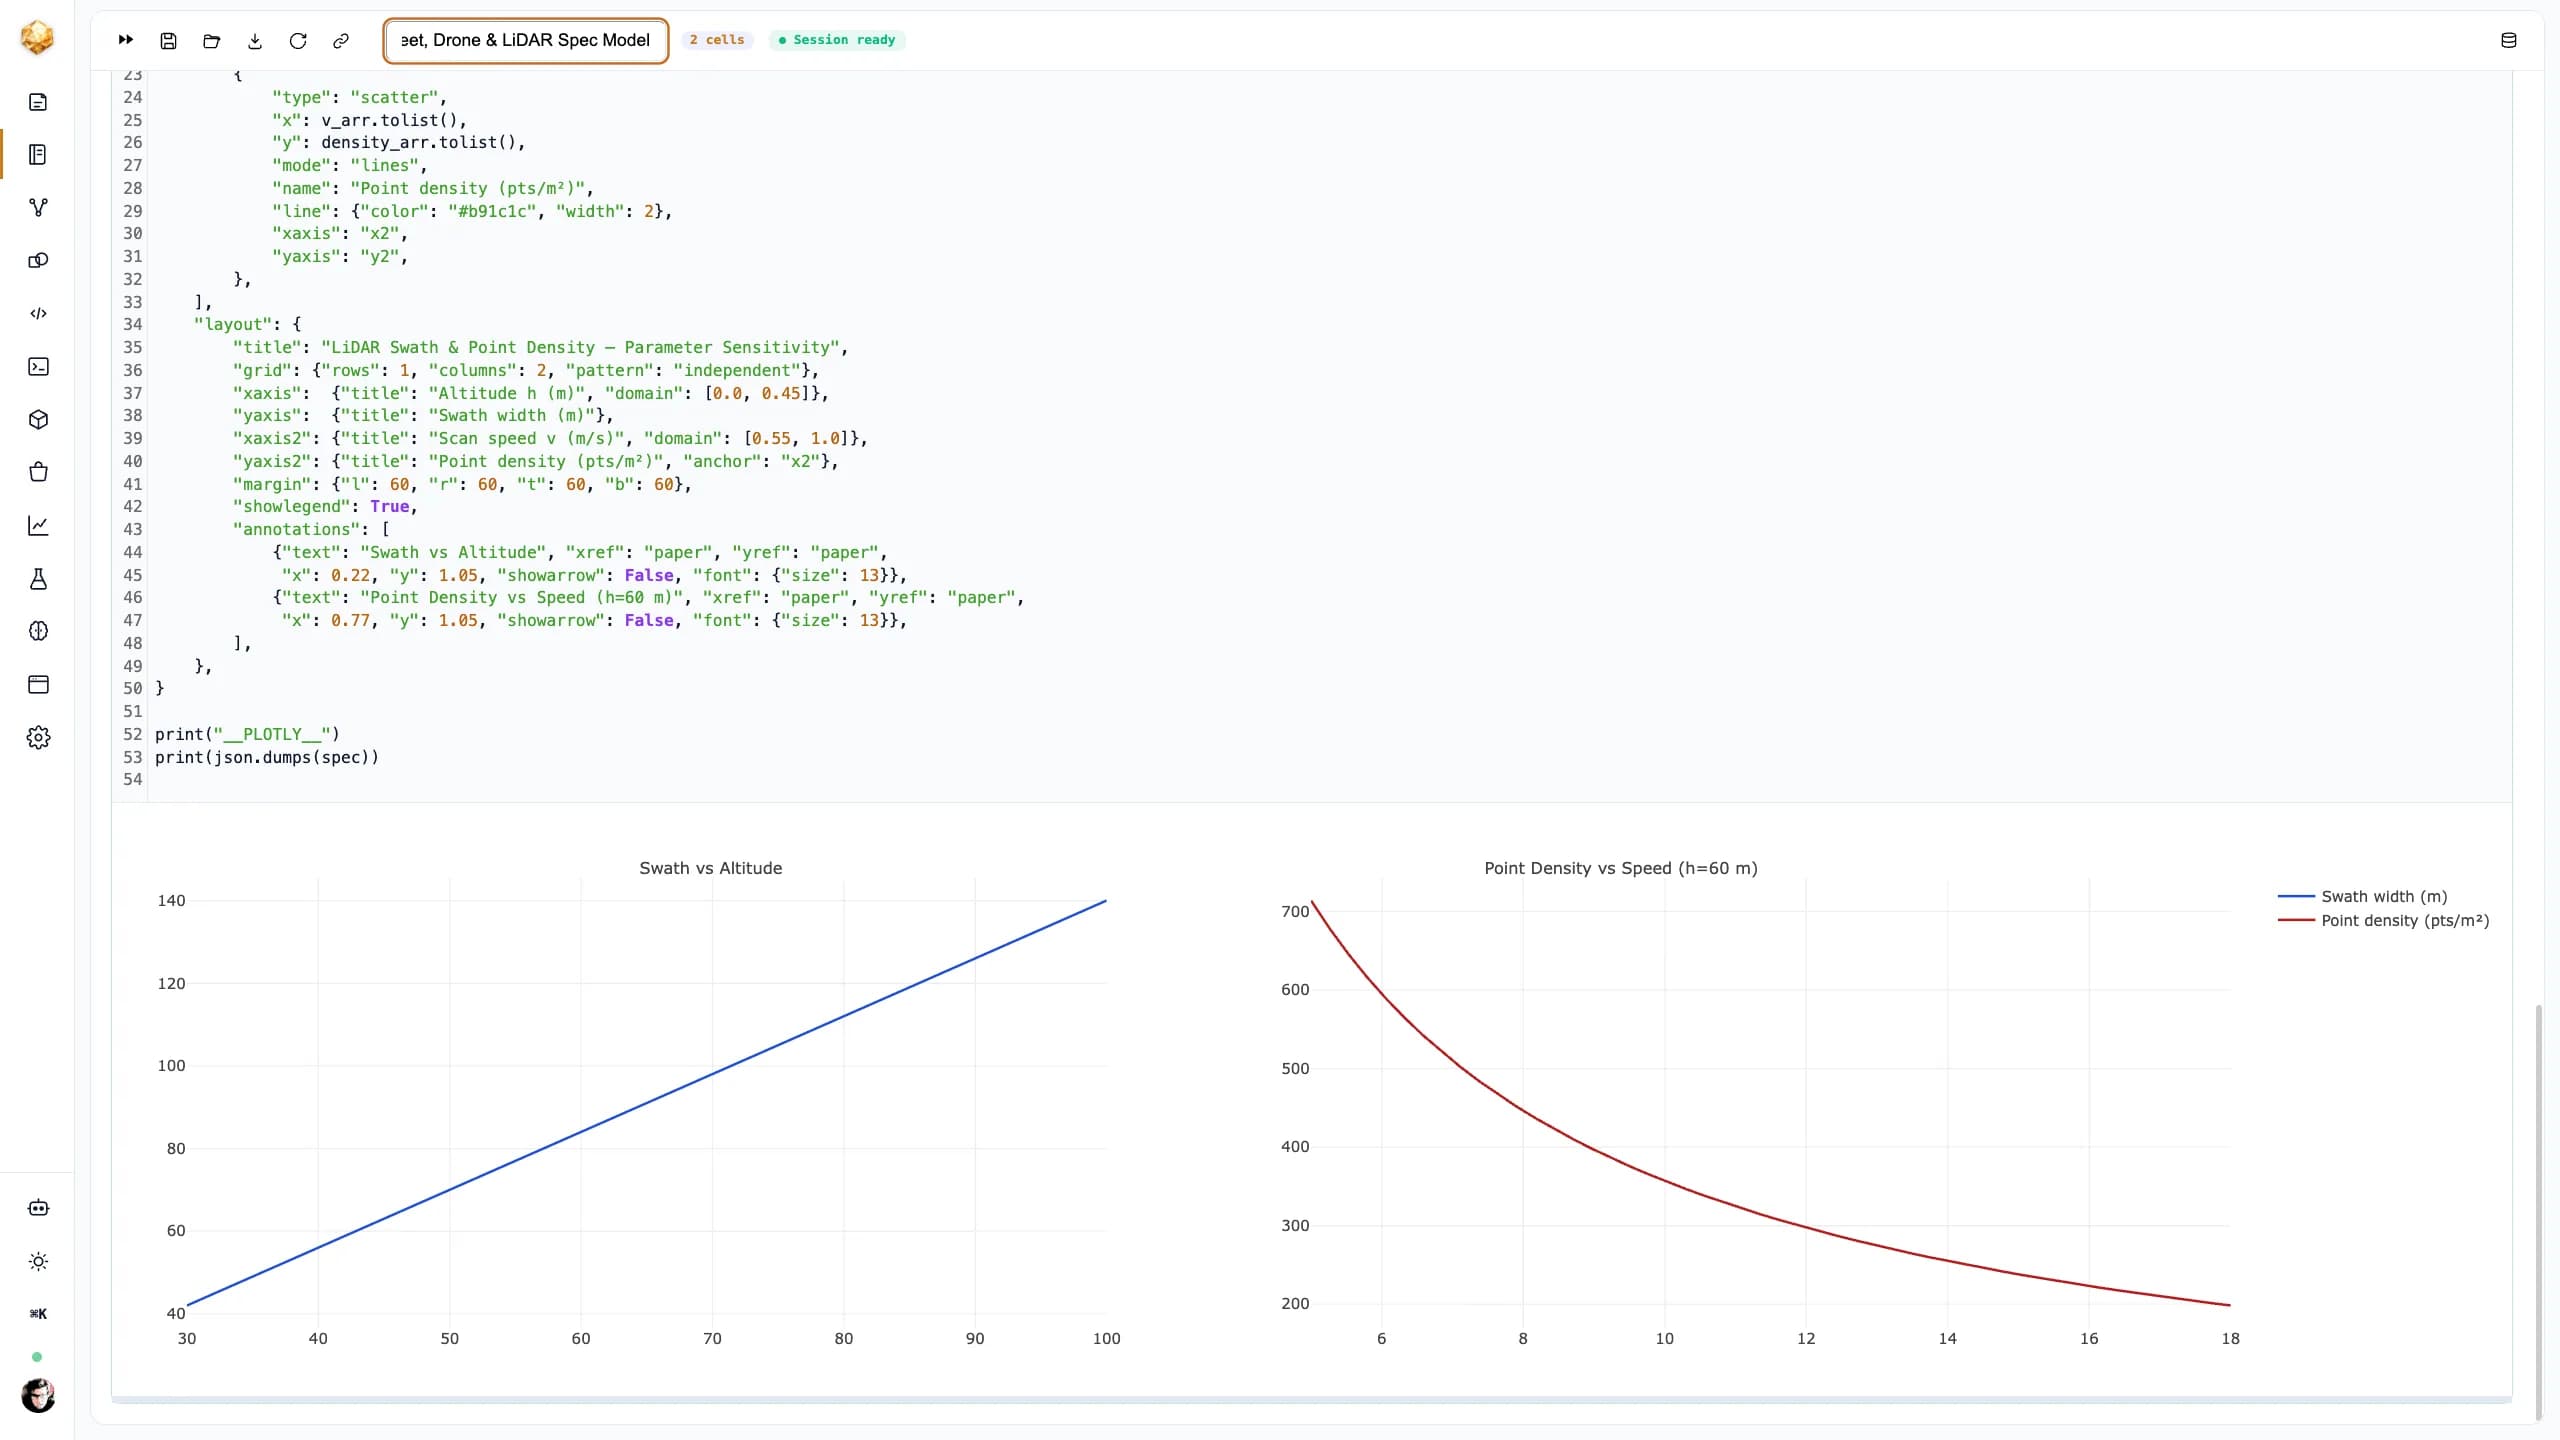
Cruise/scan speed, battery endurance and turnaround for the drone; field-of-view, point rate and minimum altitude for the LiDAR. Ground swath = 2·h·tan(FOV/2) and point density = rate / (swath · speed) fall straight out — so altitude and speed trade coverage against resolution.
Coverage path
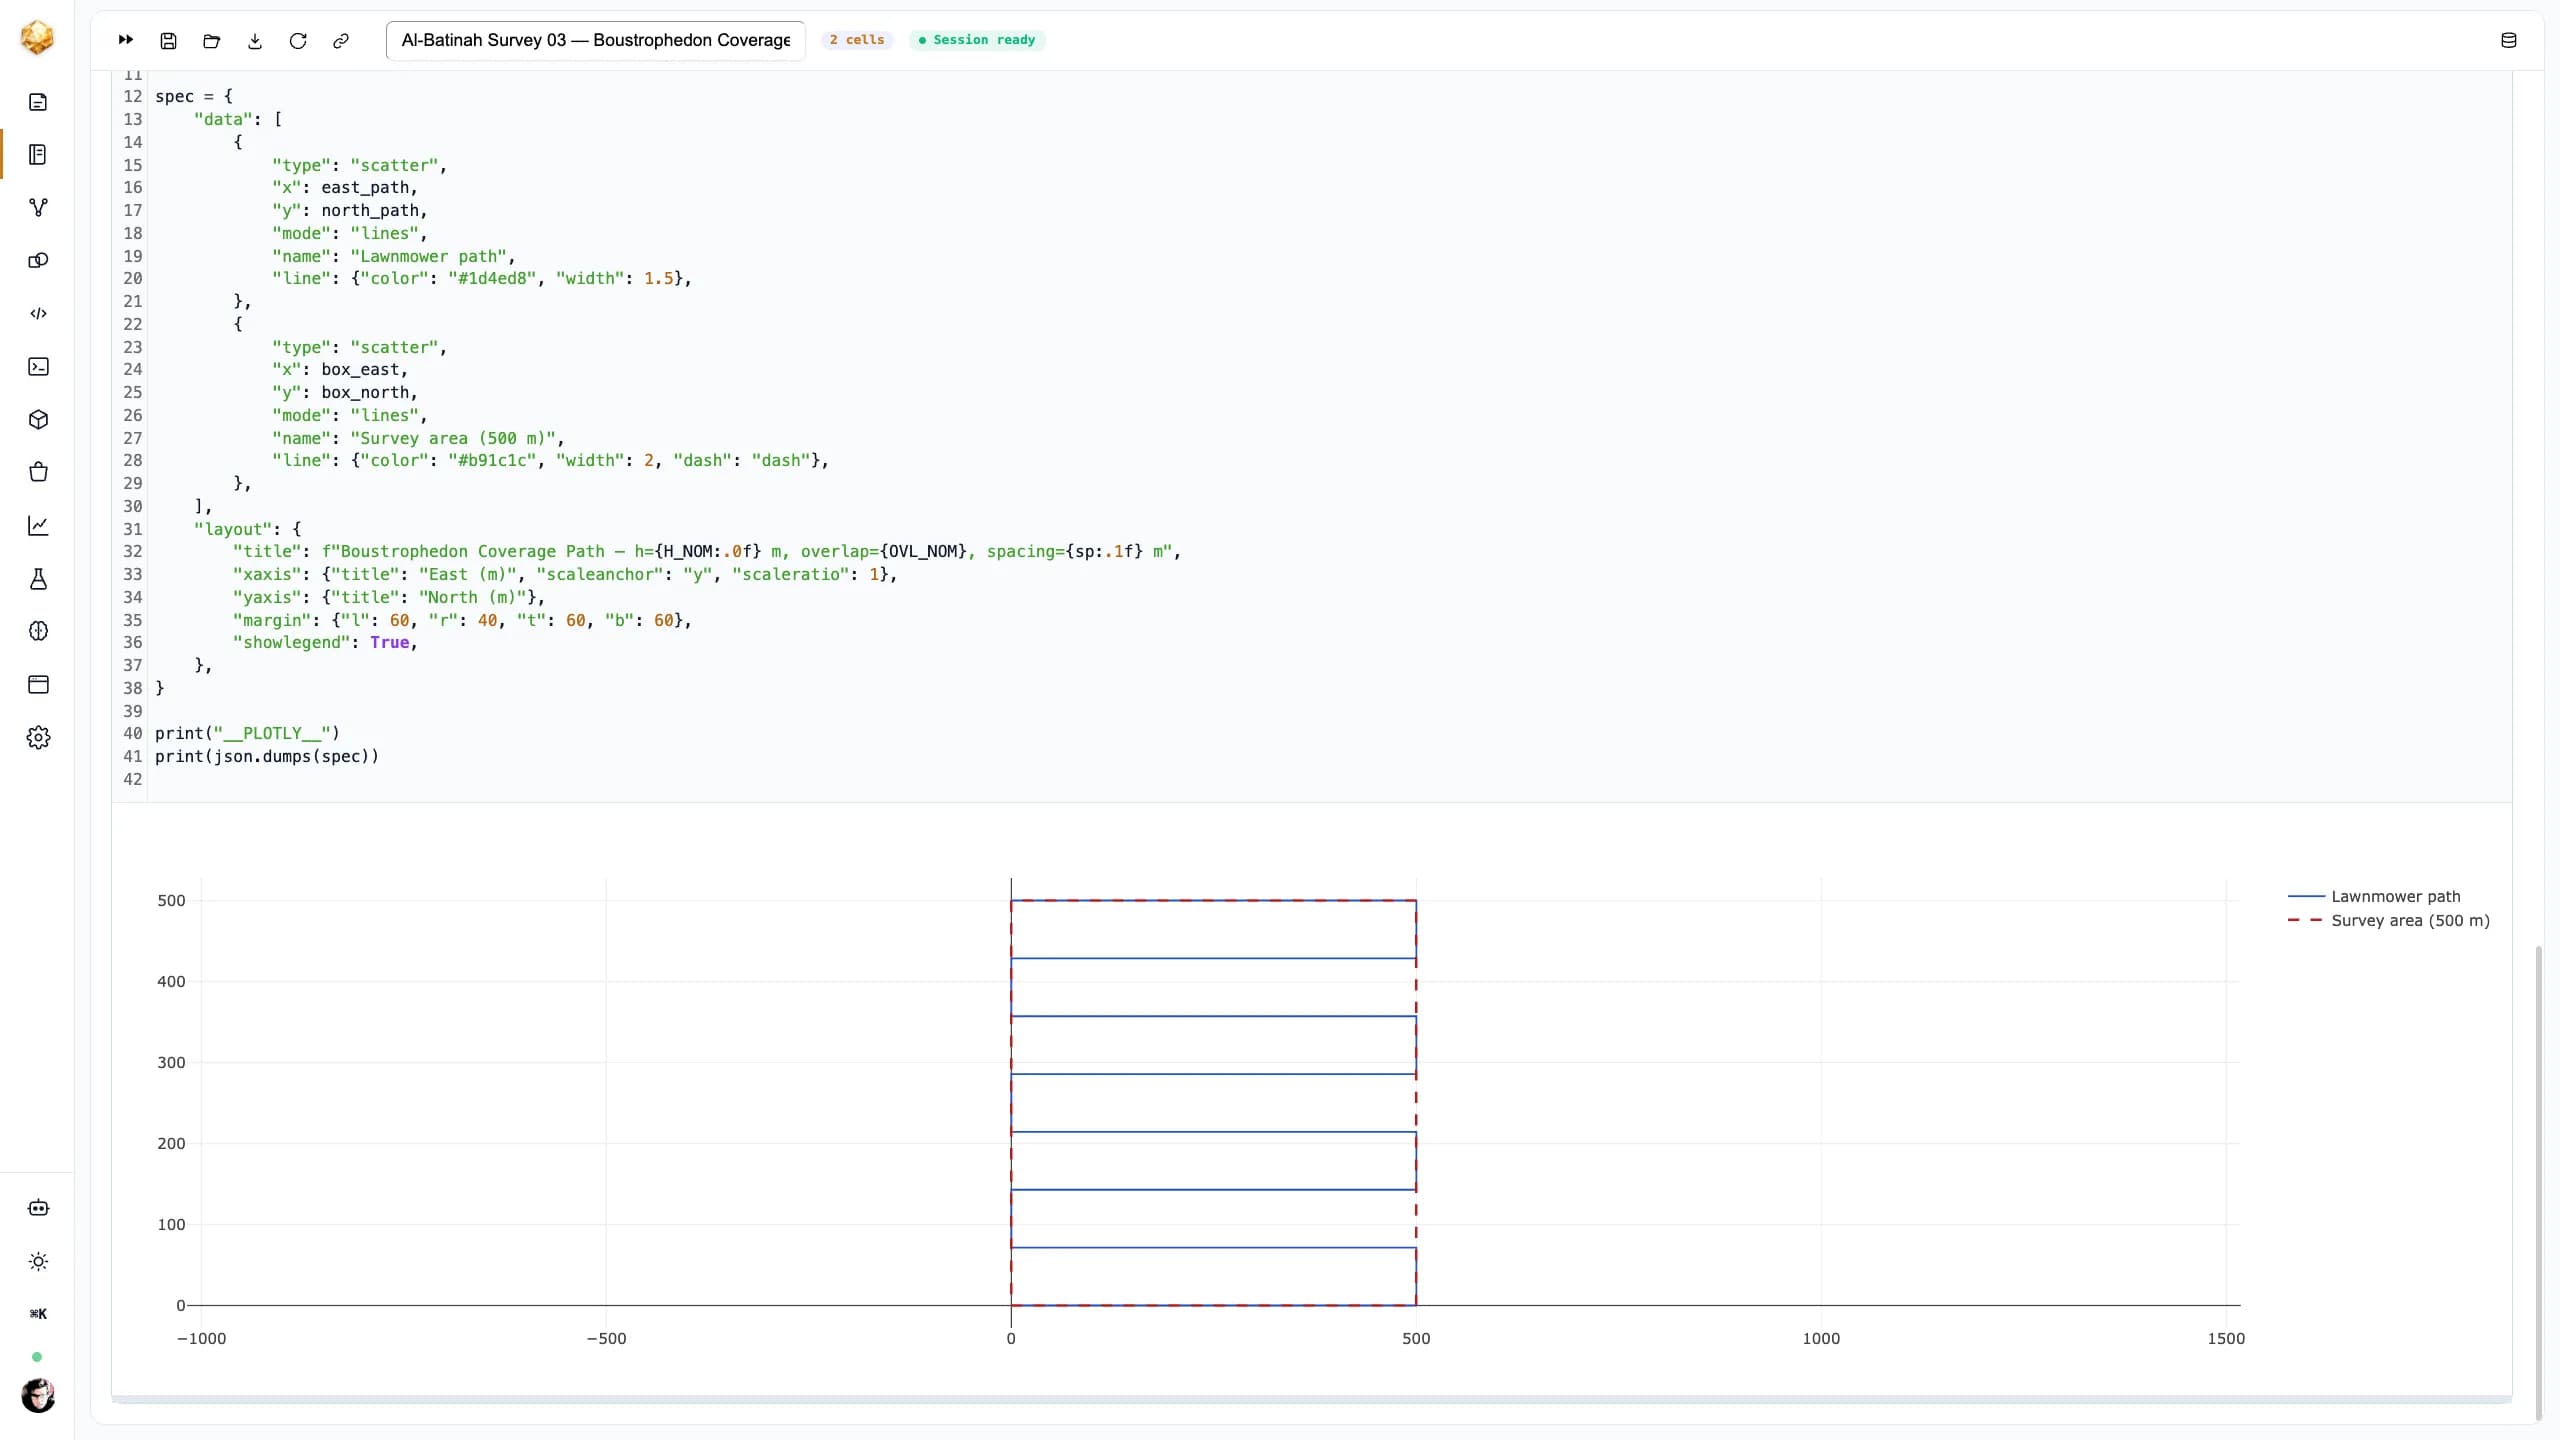
A boustrophedon (lawnmower) path tiles the box at the swath spacing implied by the chosen altitude and overlap. At 60 m and 20 % overlap that is an 84 m swath, ~8 lines and a 4.5 km scan path — the raw work the fleet has to share.
Fleet allocation & optimisation
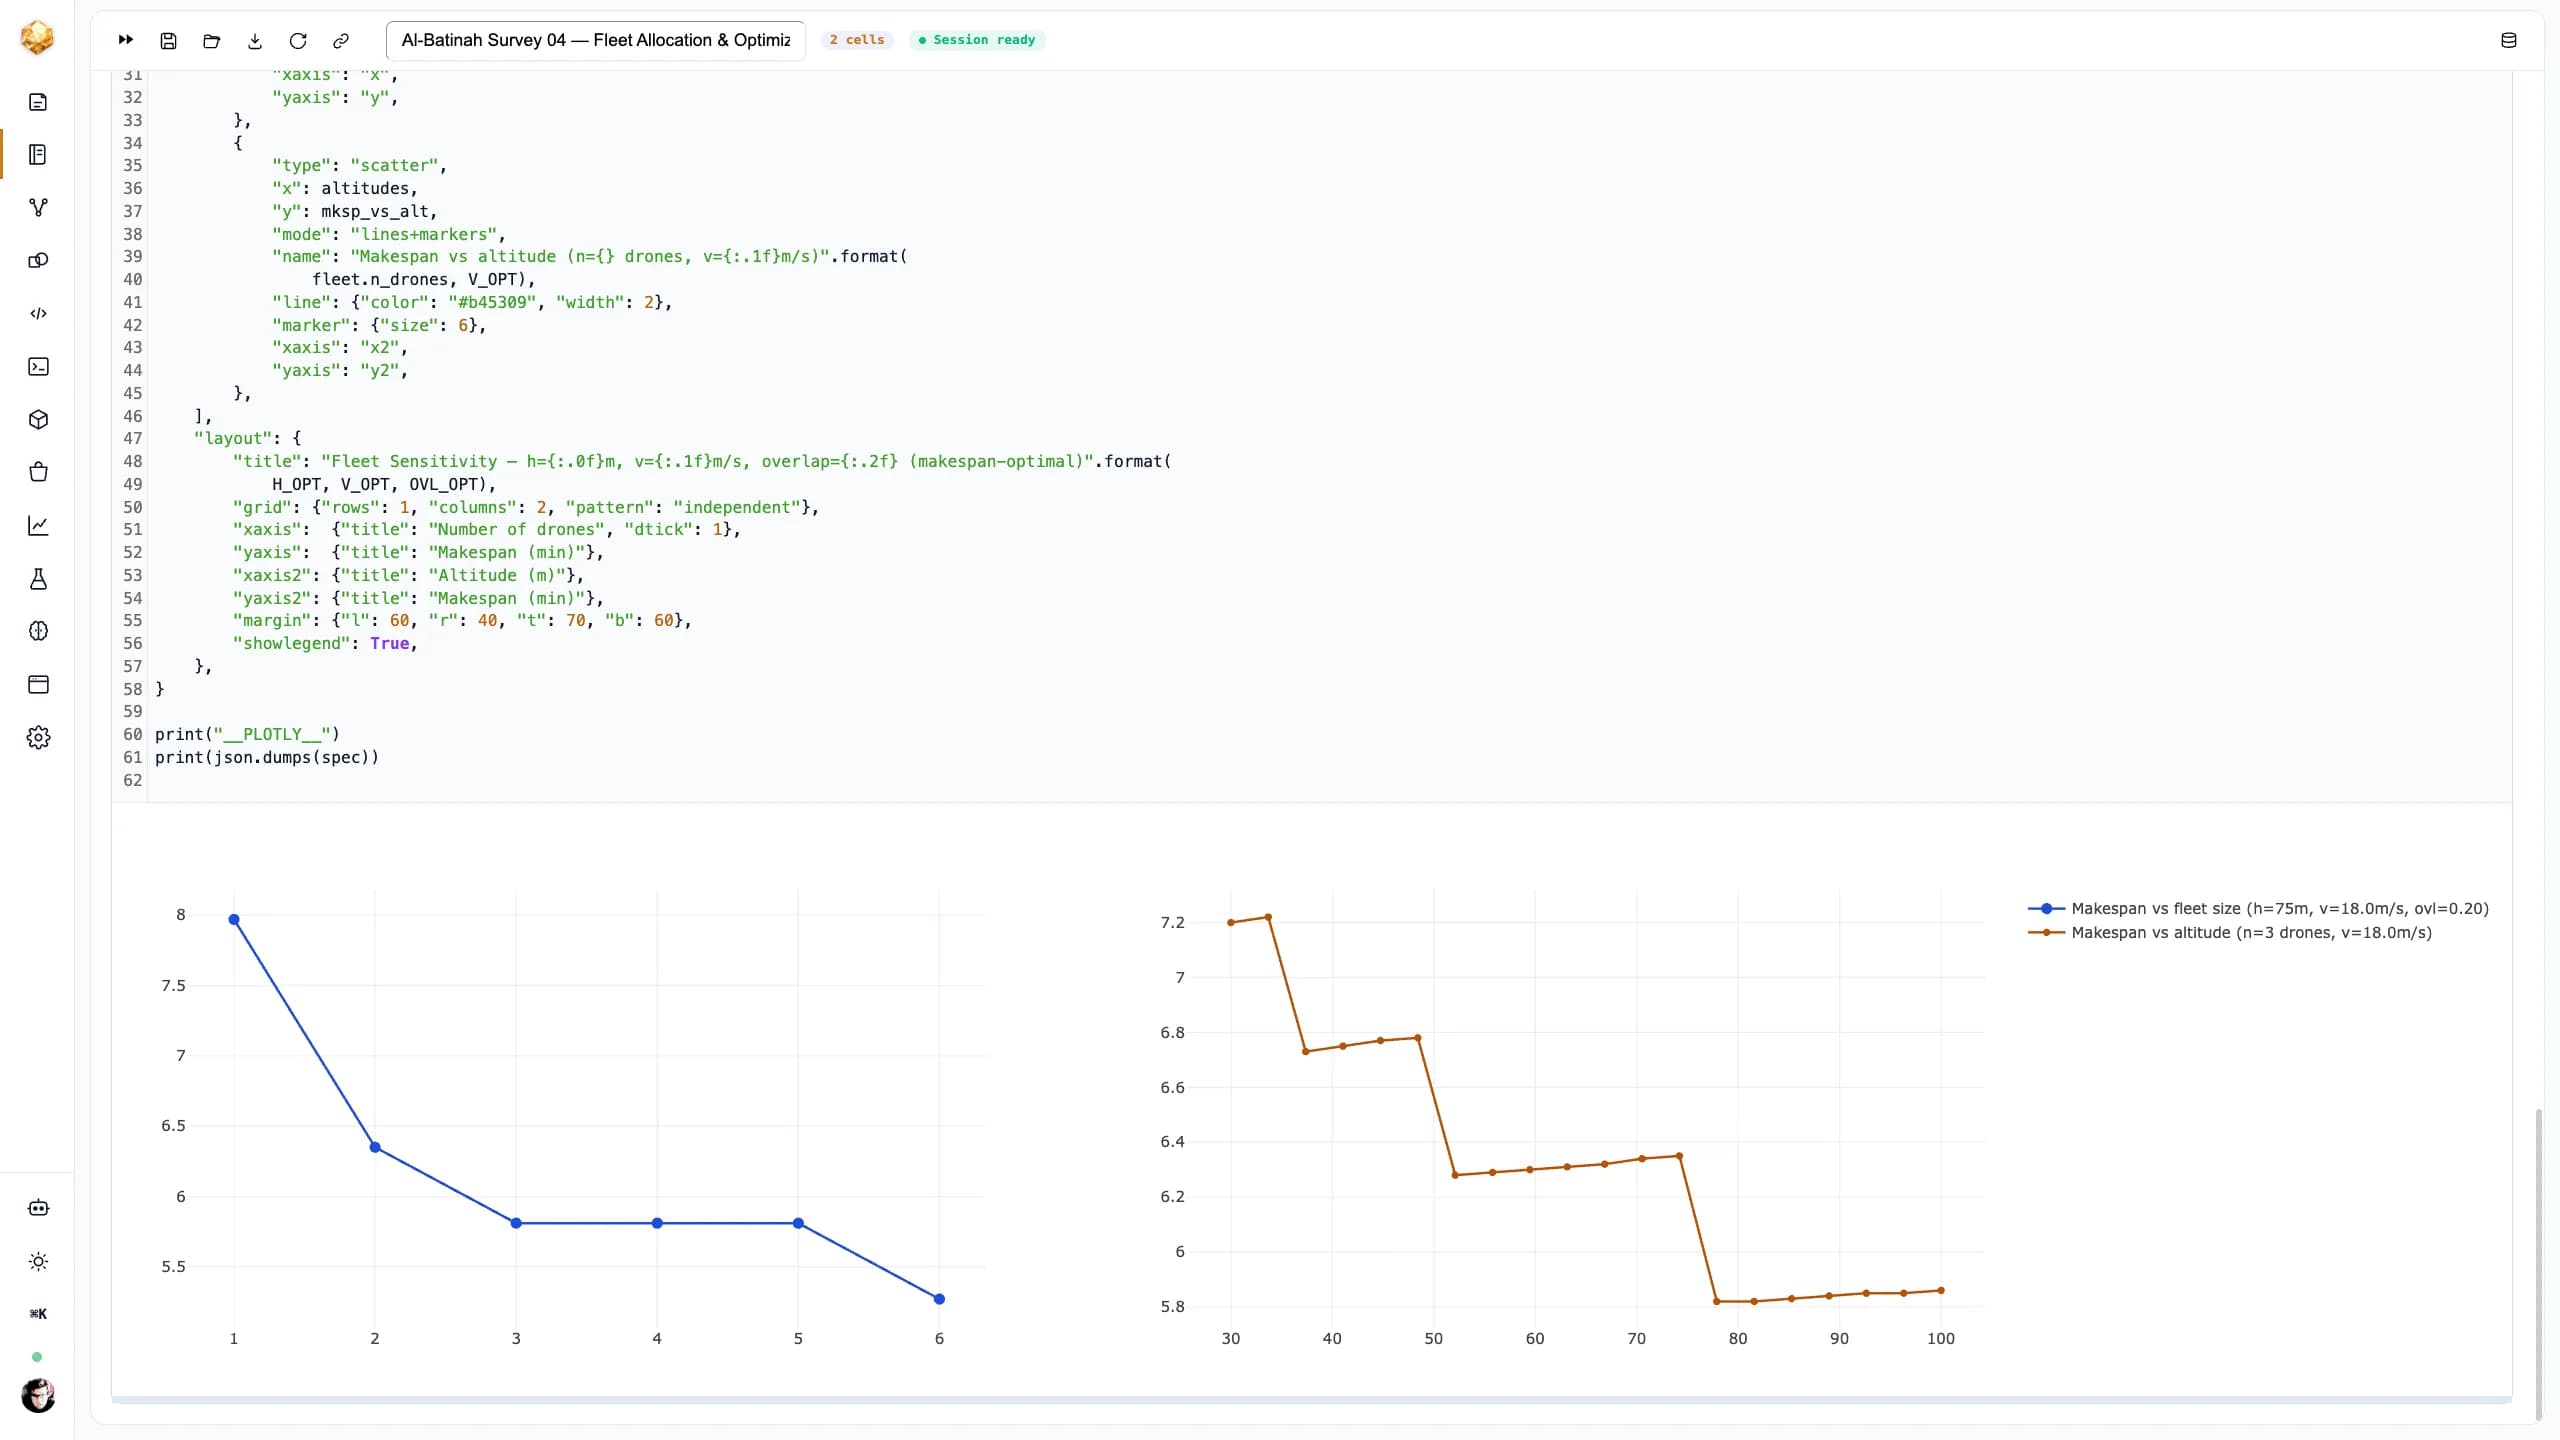
The strips are split into contiguous bands flown concurrently, so adding drones genuinely cuts the makespan. A sweep over altitude, speed, overlap and fleet size finds the optimum for the chosen objective — and shows the trade: makespan drops 34 % going from one drone to six.
Python mission → simulated fleet
The optimal plan becomes a per-drone waypoint program. A pure-Python driver commands a simulated remote fleet — arm, take off, go-to, scan, return — streaming live telemetry and a progress bar. The radio link is faked; the command structure reads exactly like the real thing.
Animated mission map
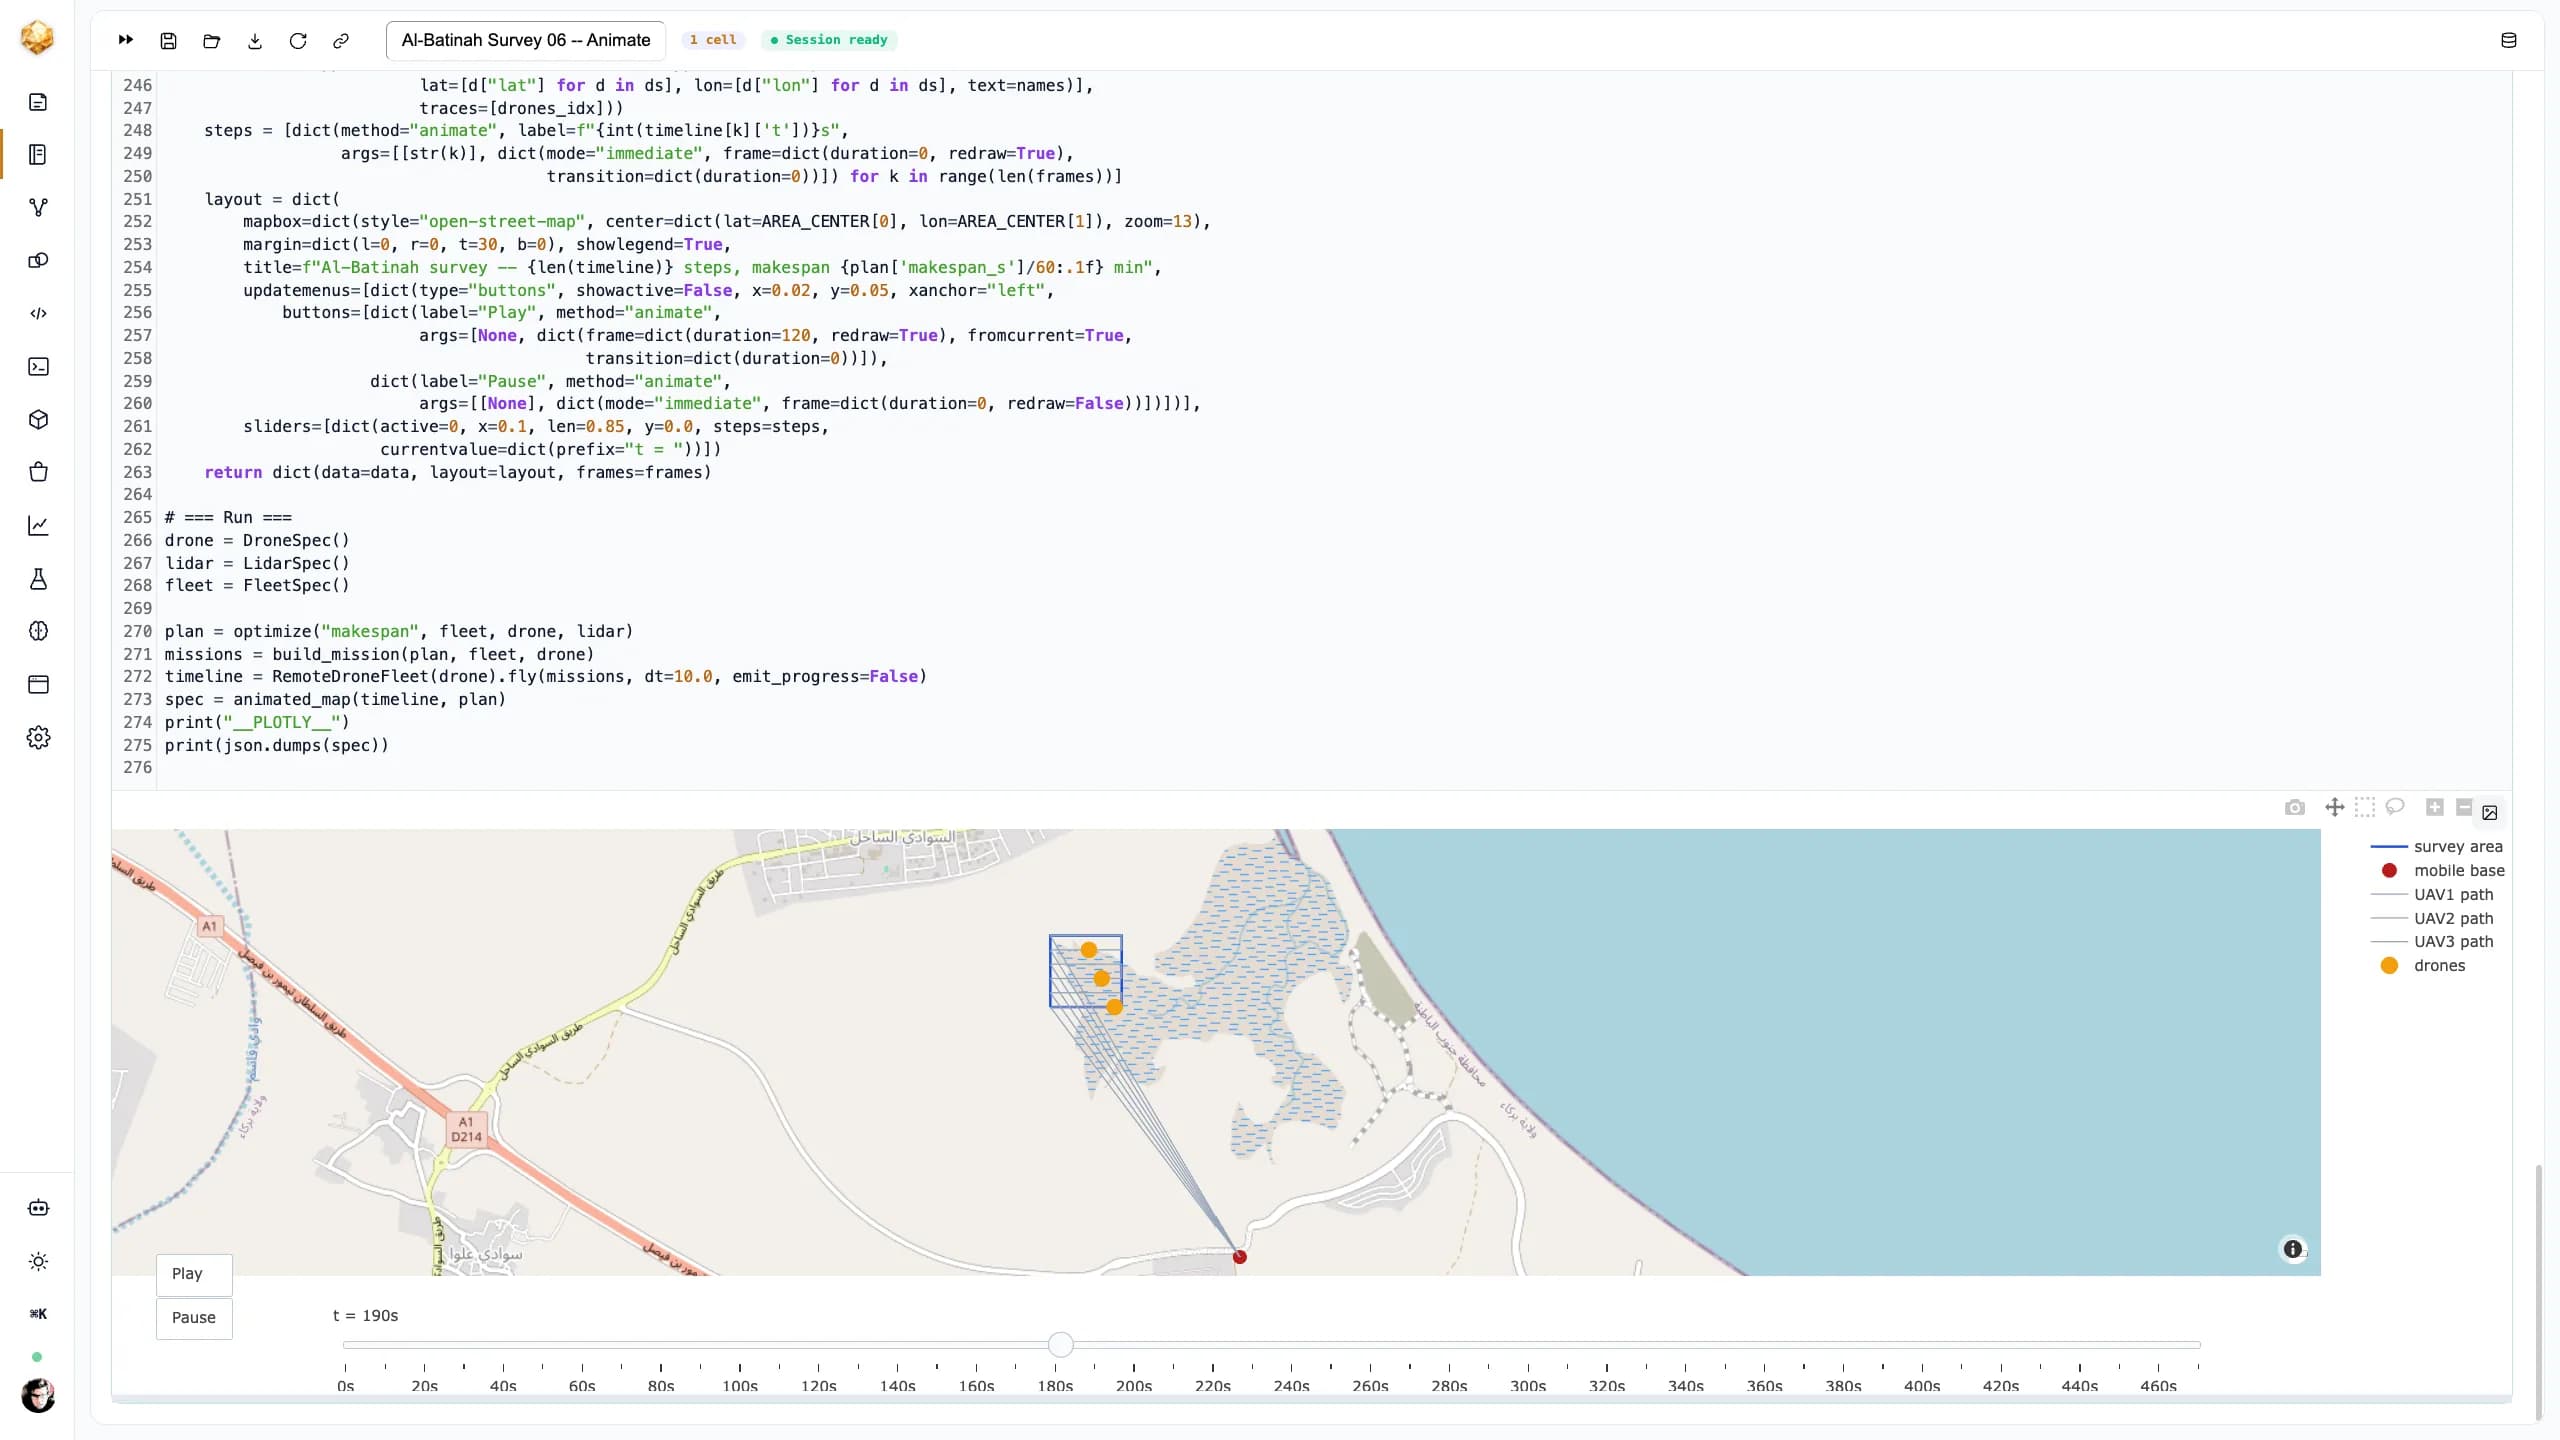
The telemetry timeline replays on an OpenStreetMap basemap: three UAVs launch from the base, transit, scan their bands concurrently and return, with a play button and time-scrubber over 48 frames. The headline artefact a planner can actually watch.
Specs in, mission out — change one number and re-plan.
The mission is a function of the hardware, not a fixed plan. The drone's endurance sets how much of the survey fits in one sortie; the LiDAR's field-of-view and point rate set how wide each pass is and how dense the returns are; altitude and speed trade the two off against each other. Because every downstream step reads these specs, swapping in a different drone or sensor — or relaxing the overlap — re-derives the swath, the path, the sortie count and the optimal fleet automatically. The plots below are the levers a planner actually turns.
Ground swath grows linearly with altitude; point density falls with altitude and speed.
Endurance minus the ~2.3 km round-trip transit sets the per-sortie scan budget.
Overlap, altitude and speed are the continuous knobs the optimiser sweeps.
One model. Three objectives. You choose what 'optimal' means.
The same plan can be optimised three ways: minimise mission time (makespan), minimise battery sorties, or maximise LiDAR resolution within a time budget. The fleet flies concurrently — strips split into contiguous bands — so the makespan objective genuinely rewards more drones, while the resolution objective drives the altitude down at the cost of time. A sensitivity sweep over fleet size and altitude makes the trade visible, so the choice is an engineering decision, not a guess.
Concurrent banding: makespan = the busiest drone's wall-time, so a bigger fleet finishes sooner.
Makespan falls from 8.0 min (1 drone) to 5.3 min (6 drones) at the time-optimal altitude.
Resolution-first pushes altitude to its floor — higher point density, longer mission.
Three objectives, three missions.
The same 500 m survey, optimised three ways for the default UR-class fleet. Minimising time flies high and fast; maximising resolution flies low and slow. (Here, fewest-sorties and best-resolution coincide at the altitude floor.)
Minimise mission time
Altitude: 75 m · Mission time: 5.8 min · LiDAR density: ≈159 pts/m²
Fewest battery sorties
Altitude: 30 m · Mission time: 13.0 min · LiDAR density: ≈1 322 pts/m²
Maximise resolution (≤ 90 min)
Altitude: 30 m · Mission time: 13.0 min · LiDAR density: ≈1 322 pts/m²
A planning digital twin, not a flight system.
Everything here is simulation. The UAV fleet is faked — there is no radio link or autopilot; the Python driver mimics a real go-to/telemetry command interface but talks to a stub. The flight model is planning-grade: flat ground, no wind, a simplified energy budget, and an optimum found within the swept parameter ranges. What it is good for is exactly what a mission planner needs before anyone flies: sizing the fleet, choosing the altitude and speed, and seeing the time/resolution trade-off — on a real site, with your own drone and sensor numbers, in minutes.
 Djinious