 Djinious





FMI co-simulation
Importing and co-simulating vendor models through the FMI standard — load a Dymola FMU and run it, cross-validate it against a native model, wrap your own controller around the black box through the FMI interface, couple it into a larger system, and quantify the co-simulation error.
 DjiniousLab
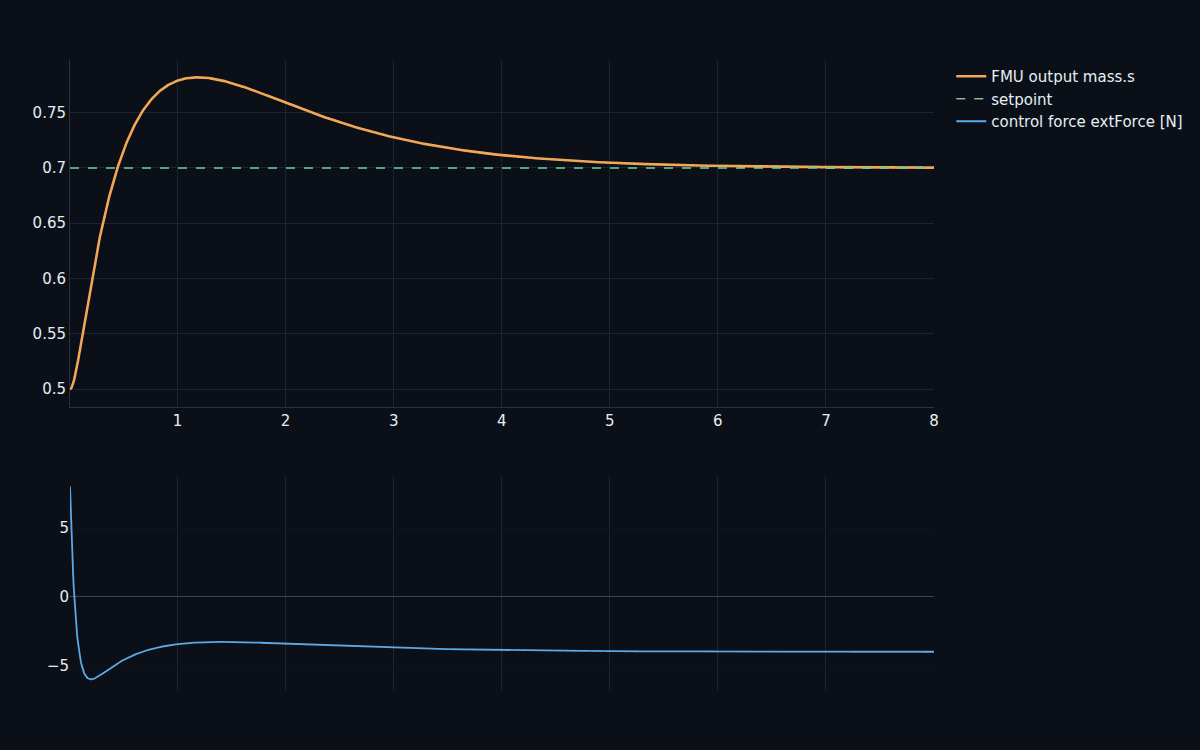
- closed-loop tracking error on a vendor FMU
- 2.9e-4 mclosed-loop tracking error on a vendor FMU
- CS-vs-ME agreement (RMSE)
- 1.3e-3 mCS-vs-ME agreement (RMSE)
- FMU-vs-native fidelity (RMSE)
- 4.7e-3 mFMU-vs-native fidelity (RMSE)
- co-sim error cut by macro-step refinement
- 7.6×co-sim error cut by macro-step refinement
- design notebooks
- 10design notebooks
- requirements PASS
- 5 / 5requirements PASS
Run — and control — a model you didn't build.
No team models everything in one tool. The FMI standard exists so a model built in Dymola, Simulink or anywhere else can be packaged as an FMU and run somewhere else entirely. This program is the import side of that promise: load a vendor FMU into DjiniousLab's Julia worker, co-simulate it, cross-validate it against a native re-implementation, and — the part that matters — wrap your own controller around the black box and close the loop through the FMI interface. Interoperability isn't a checkbox; it's controlling someone else's model as if it were yours.
Drop in a vendor FMU and it just runs.
An FMU is a self-contained, compiled model behind a standard C interface. The first notebook loads a Dymola-exported reference FMU into the Julia worker and co-simulates it — states out, phase orbit closed, no source code, no re-derivation. That's the baseline interoperability claim: a model authored in another tool, running here, unchanged.
DjiniousLab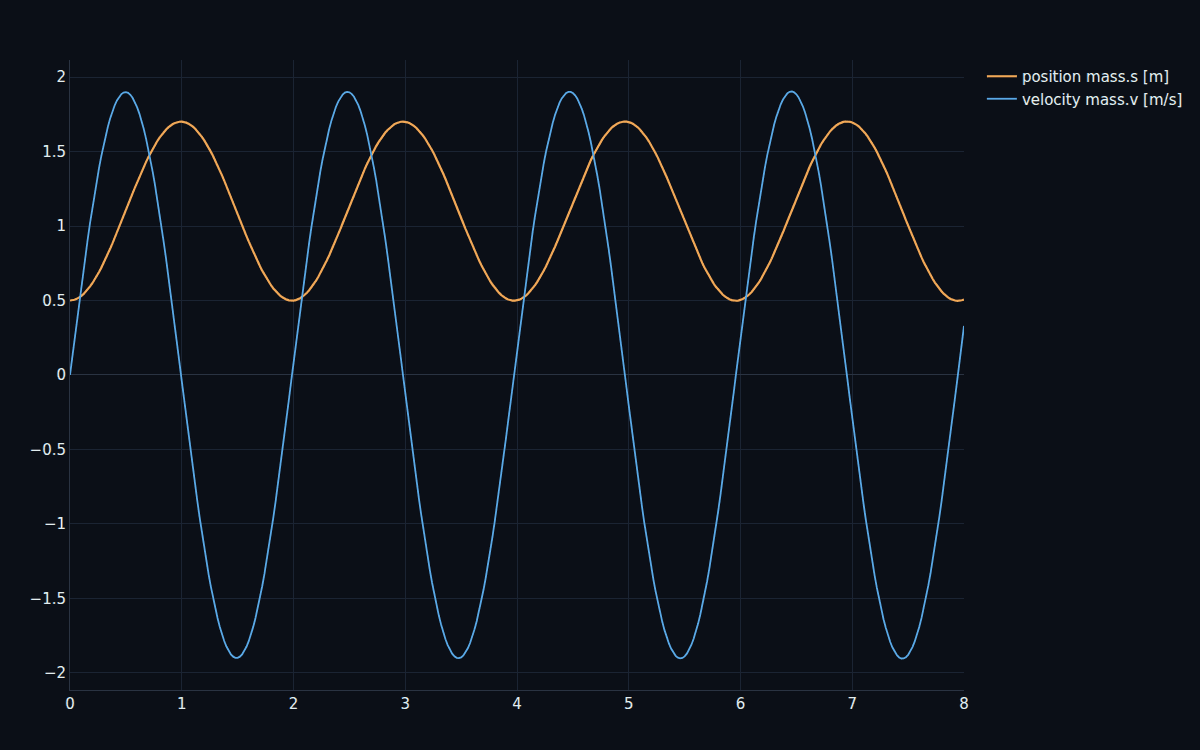
Co-simulation or model-exchange — and they agree.
FMI offers two modes. In co-simulation the FMU carries its own solver and you call doStep; in model-exchange your solver integrates the FMU's derivatives. The same FMU run both ways overlays to a 1.3×10⁻³ m RMSE — the choice is about who owns the solver, not about getting different answers. That equivalence is what lets you mix an FMU into a larger Julia-solved system with confidence.
DjiniousLab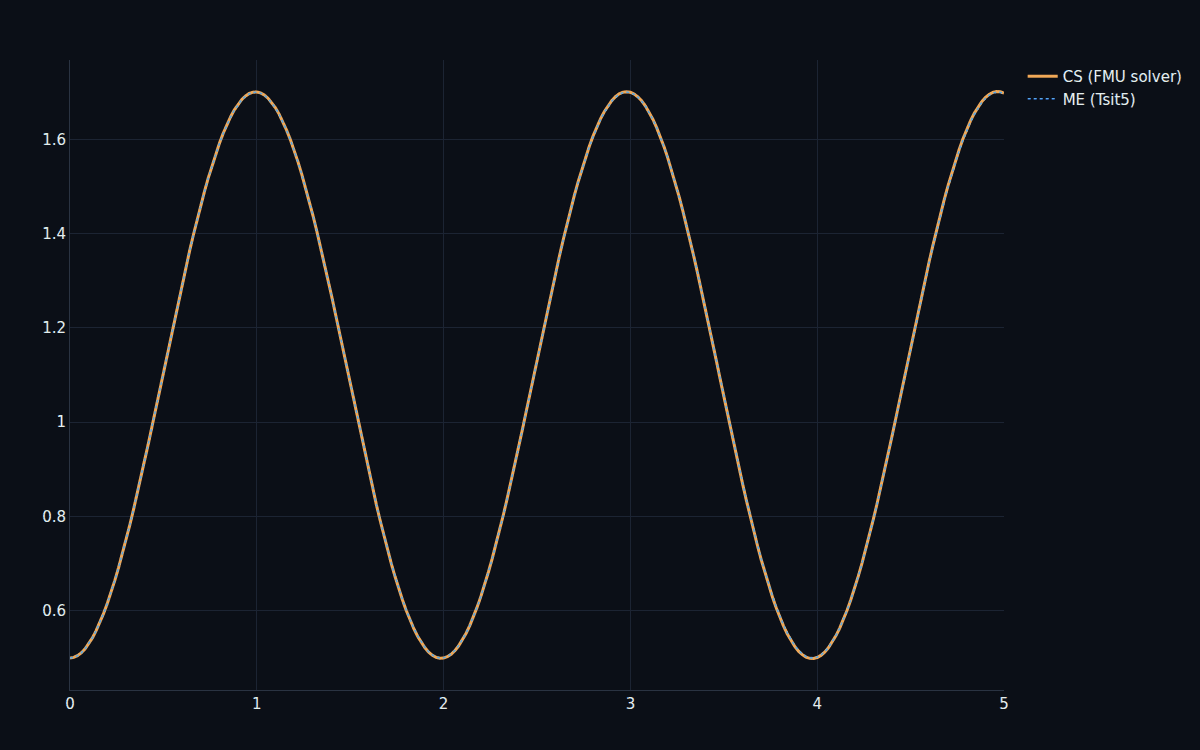 DjiniousLab
Close a loop around the black box.
The strongest interoperability claim isn't running a vendor model — it's controlling one. The hero notebook makes the imported FMU the plant and wraps a native Julia PID around it through a manual co-simulation loop: read the FMU's output, compute the control, set the FMU's input, step. The controller never sees inside the FMU; it only talks to it through the FMI interface — and drives it to a setpoint with 2.9×10⁻⁴ m tracking error. That's a controller and a vendor plant from two different worlds, meeting at the standard.
DjiniousLabCo-simulation has its own error budget.
Coupling models at discrete communication points introduces an error all its own: between steps, each model sees its inputs held constant, so a too-large macro step lags and distorts. The program quantifies it — halving the macro step roughly halves the error (first-order convergence), a 7.6× reduction across the sweep. Knowing that error is first-order in the step size is what lets you trade accuracy against speed deliberately instead of by accident.
DjiniousLab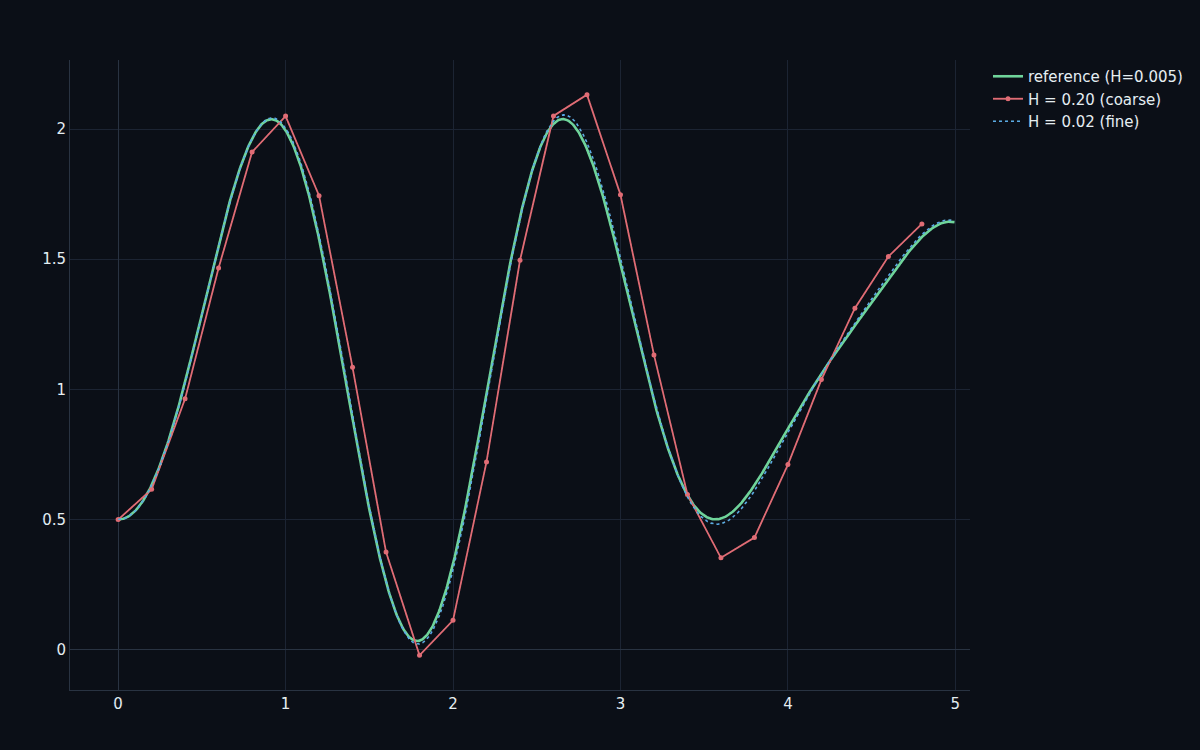
Every number re-derived at sign-off.
The V&V notebook re-imports the FMU and re-derives each requirement from scratch, printing a PASS/FAIL board.
Result
- Import & co-sim a vendor FMU: 101 samples
- CS vs ME agreement: 1.3e-3 m RMSE
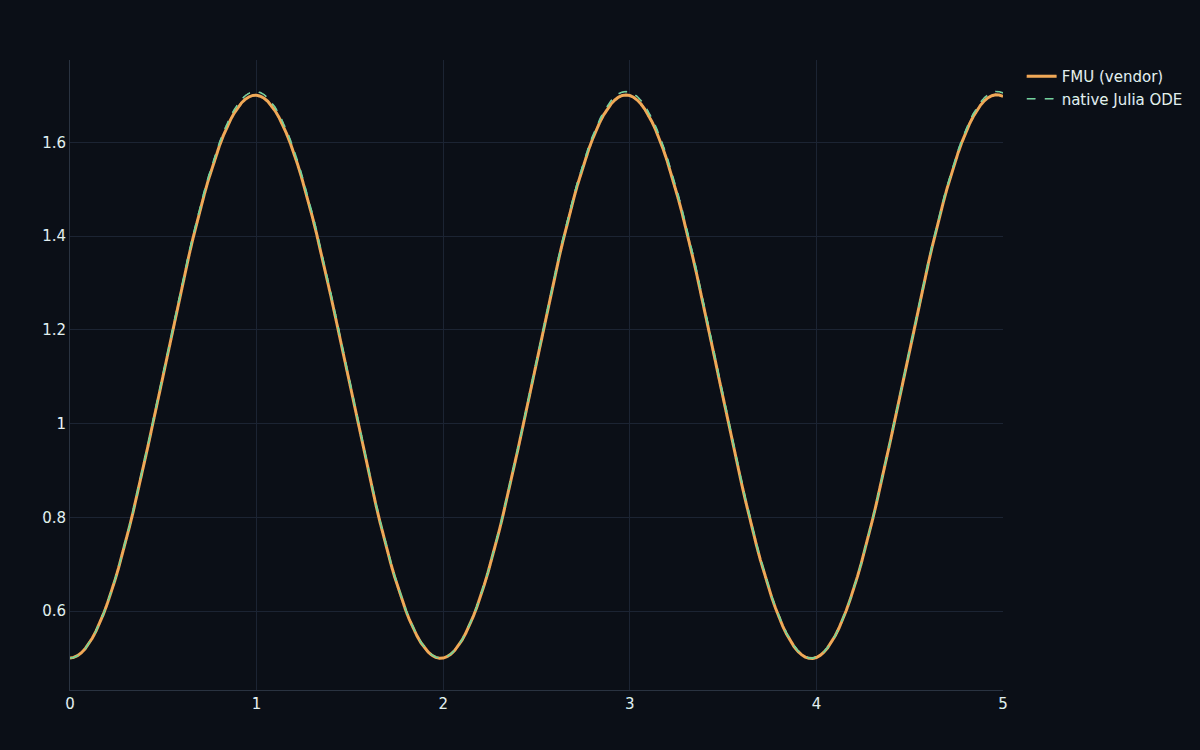
- FMU vs native fidelity: 4.7e-3 m RMSE
- Closed-loop tracking error: 2.9e-4 m
- Co-sim error vs macro step: 7.6× reduction
Requirement
- Import & co-sim a vendor FMU: R-01
- CS vs ME agreement: R-02
- FMU vs native fidelity: R-03
- Closed-loop tracking error: R-04
- Co-sim error vs macro step: R-05
The import side, on reference FMUs.
The deliverable is ten notebooks and the dossier — the models arrive as compiled FMUs behind the FMI C interface, not as acausal DjiniousLab components, so there's no custom block or canvas. The FMUs are Dymola-exported references rather than arbitrary third-party models; the co-simulation is single-rate with constant-input extrapolation between communication points and no algebraic-loop solver across coupled FMUs. And this is the import/co-simulate story specifically — FMU export is a separate Rust path in the platform. What the program proves is the interoperability core: load, co-simulate both ways, cross-validate, control, couple, and quantify the co-sim error — every number re-runnable, the strongest of them a native controller closing a loop around a vendor model it can't see inside.
Keep exploring
Related use cases
 Safety-critical embedded controlNine safety functions, from YAML requirement to certified embedded RustThe voter reference project takes nine safety functions — voting, latching, slew limiting, trip monitoring, interlocks and a flow gauge with a floating-point boundary — through all thirteen gates, and replays every one on an emulated Cortex-M4F.
 DjiniousSafe
 Control & reinforcement learningCart-pole control & RLThe canonical underactuated-control benchmark, taken end to end — nonlinear dynamics, an LQR that stabilises the inverted pole, energy swing-up, a model-free reinforcement-learning policy, and a Monte-Carlo robustness gate.DjiniousLab
 ElectromagneticsElectromagnetics (FDTD)Solving Maxwell's equations on a grid — the electric and magnetic fields leapfrogging through space and time. A self-contained FDTD solver reproduces the canonical wave phenomena: radiation, refraction, diffraction, scattering and cavity resonance. The field-solver sibling to CFD, in electromagnetics.DjiniousLab