 Djinious



Block-diagram canvas
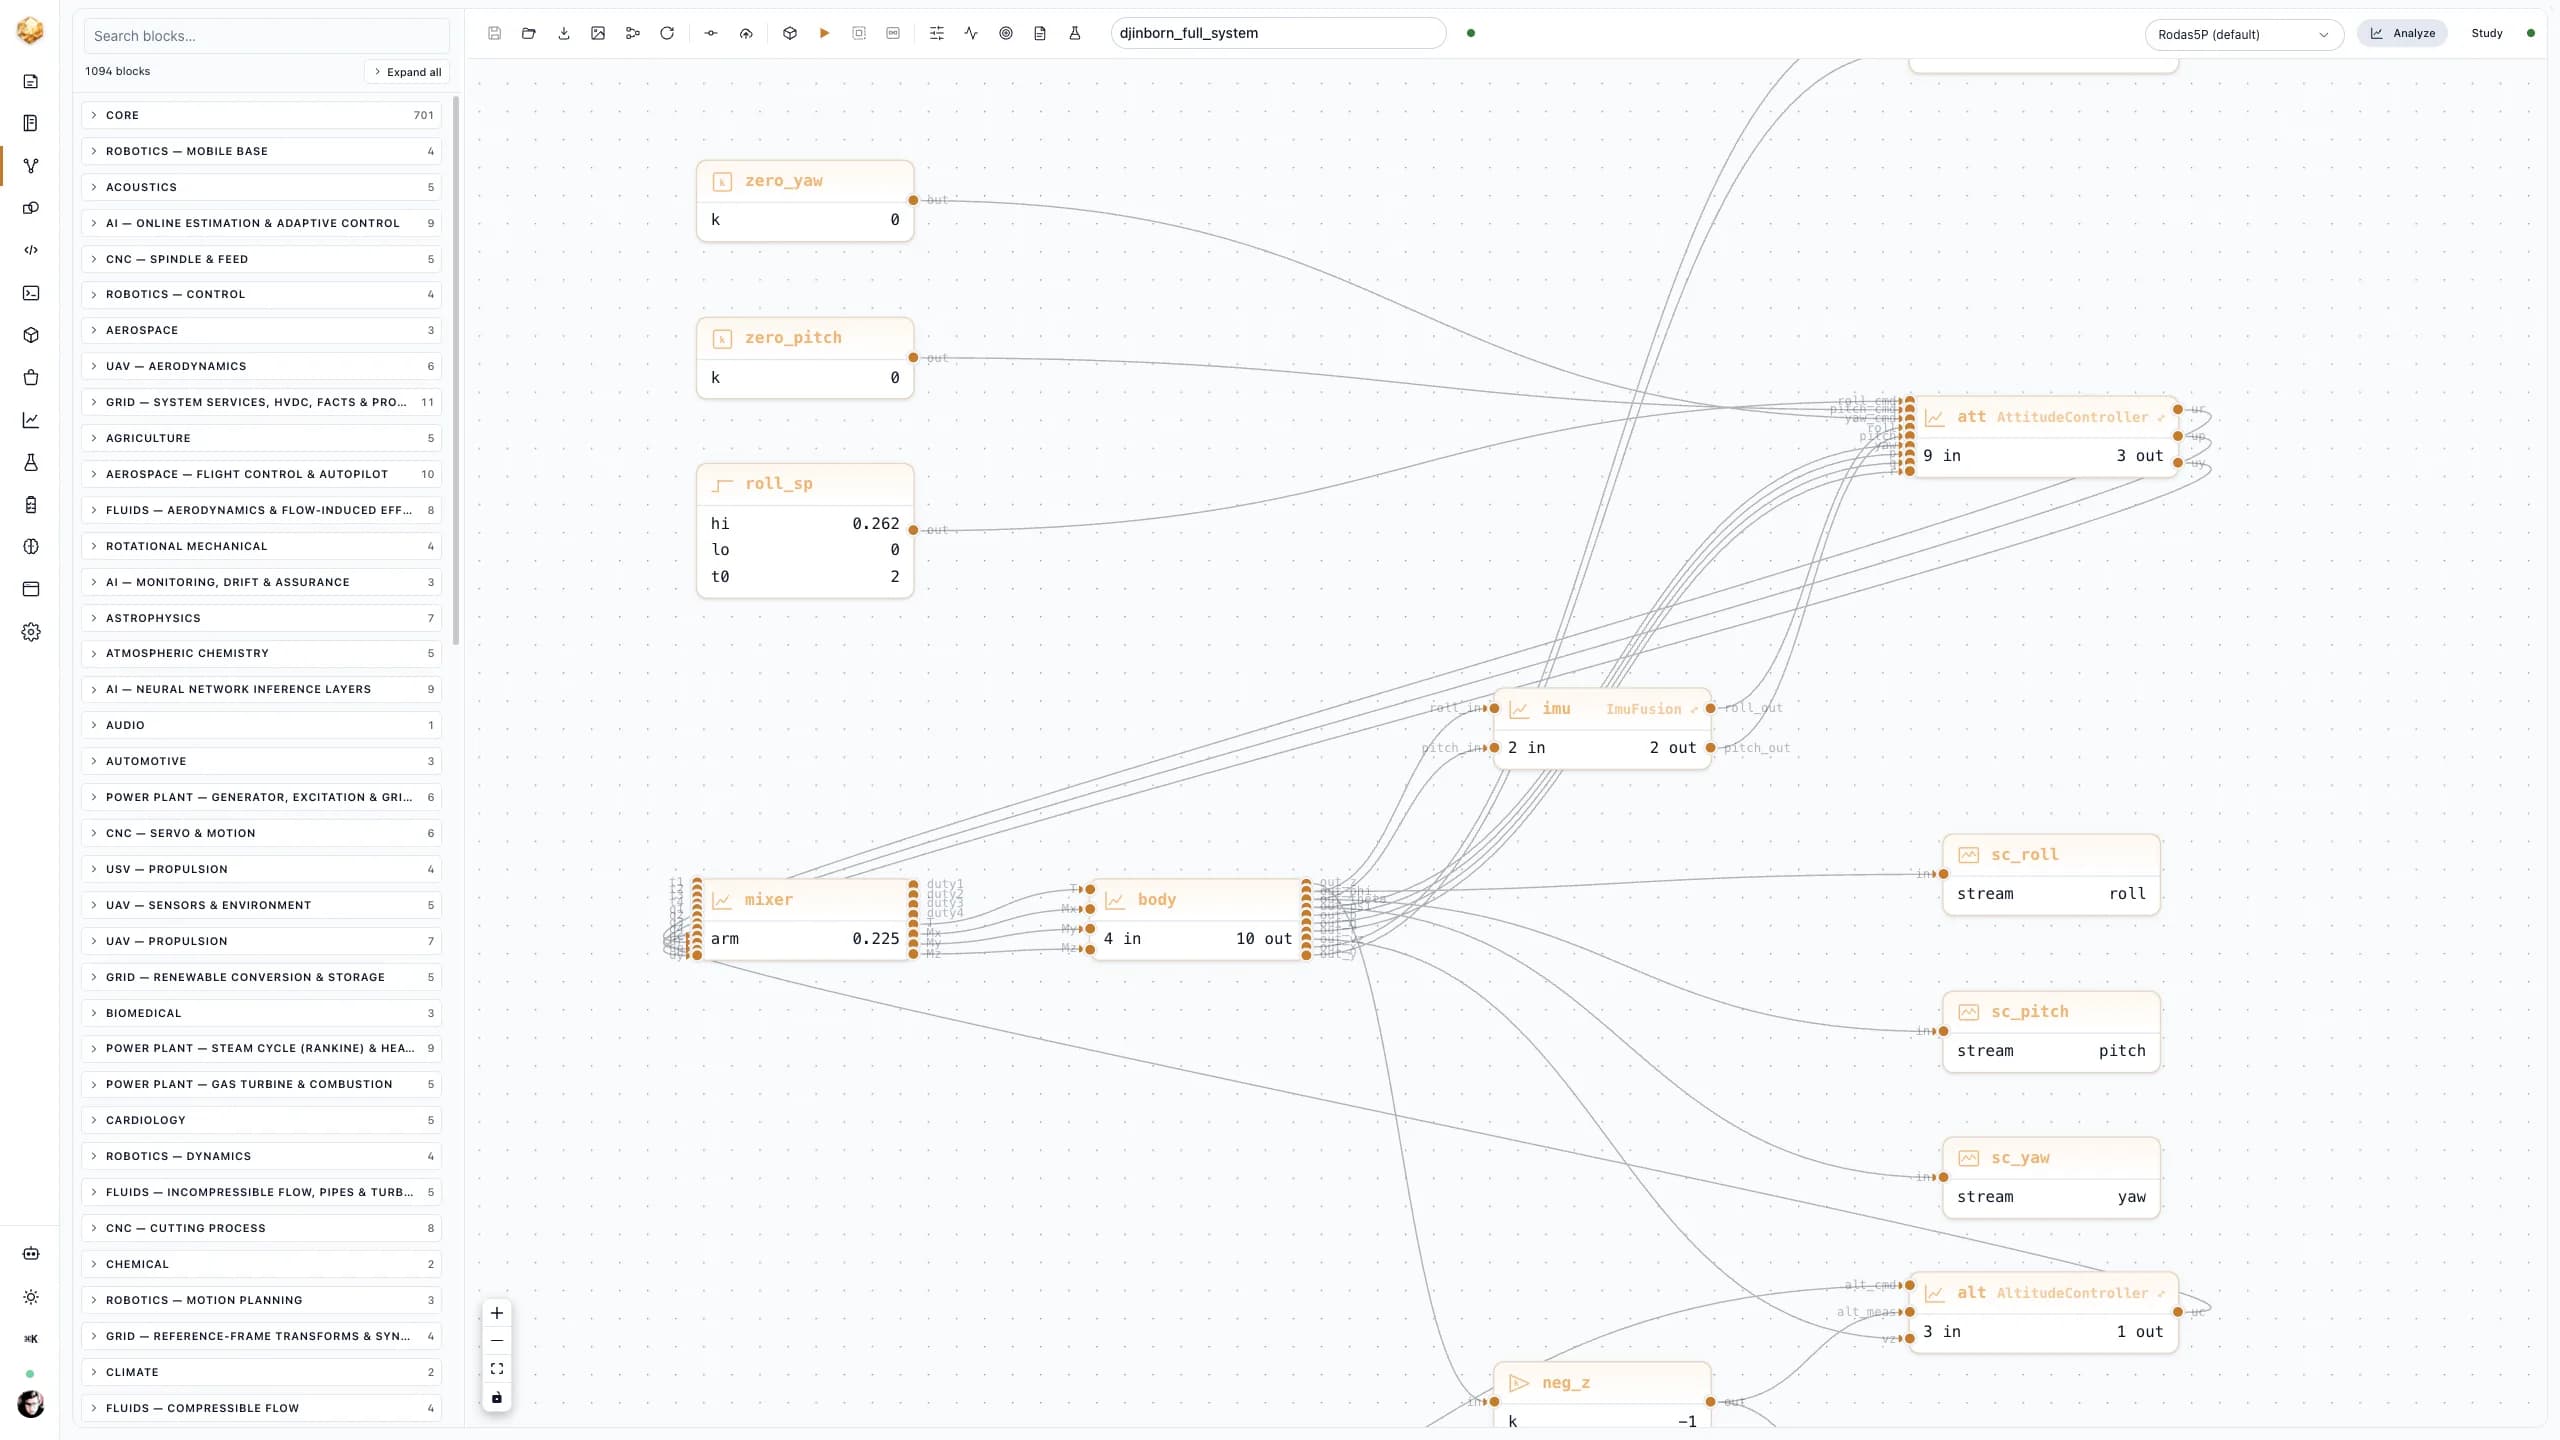
Compose multi-domain models on a fast, GPU-accelerated canvas. Acausal modelling means you draw the physics — the solver figures out the math.
AcausalThe platform
Each application does one part of the work — and hands its evidence to the next. Use them together, or one at a time.
Platform overviewSee how the loop runs DjiniousEngineeringOrchestration
 DjiniousLabModelling & simulation
 DjiniousWorkshopSystem integration
 DjiniousSafeCertifiable code
 DjiniousWorld3D replicas
 DjiniousMapAgent GIS
 DjiniousCCOperations & SCADA
 DjiniousDataKnowledge base
 DjiniousWorkflowAgent automation
 DjiniousLabModelling & simulation
DjiniousLab is one engineering notebook for model-based design. Model every aspect of your system, simulate and test it as a living digital replica, then generate the embedded software — and the physical parts — that ship.
 DjiniousLab
What it is
A digital replica is a high-fidelity, executable model of your system — physics, control logic, geometry, and all. In DjiniousLab it lives in one notebook, so the model you design, the replica you test, and the artefacts you ship never drift apart. Model, simulate, and generate are a single closed loop, not three disconnected tools.
Compose multi-domain models on a fast, GPU-accelerated canvas. Acausal modelling means you draw the physics — the solver figures out the math.
AcausalEdit any upstream cell and every dependent cell re-evaluates automatically; a persistent REPL lets you interrogate live state without re-running the notebook.
Julia · Pythonthe3djin brings a BuildPart / ParameterSet API to the notebook: revolve, extrude, loft, fillet, chamfer, and boolean ops in plain Python, with STEP/STL export.
the3djinParameter sweeps, CMA-ES / Bayesian optimisation, and PPO/SAC reinforcement learning run from the Studies panel, alongside the canvas.
StudiesCompile any model to deterministic #![no_std] Rust firmware for STM32, Cortex-M, ESP32/RISC-V, WASM or x86-64 — built in, not a paid add-on.
no_std RustEvery run is branded with its GIR hash — reproducible, auditable, bit-exact on replay.
GIR hashInside the product
Every capture below is the running product.
01 · Canvas
Compose multi-domain models on a fast, GPU-accelerated canvas. Acausal Simscape-class modelling means you draw the physics — the solver figures out the math. Algebraic-loop detection and Pantelides index reduction happen at compile time, not at 3 AM.
DjiniousLab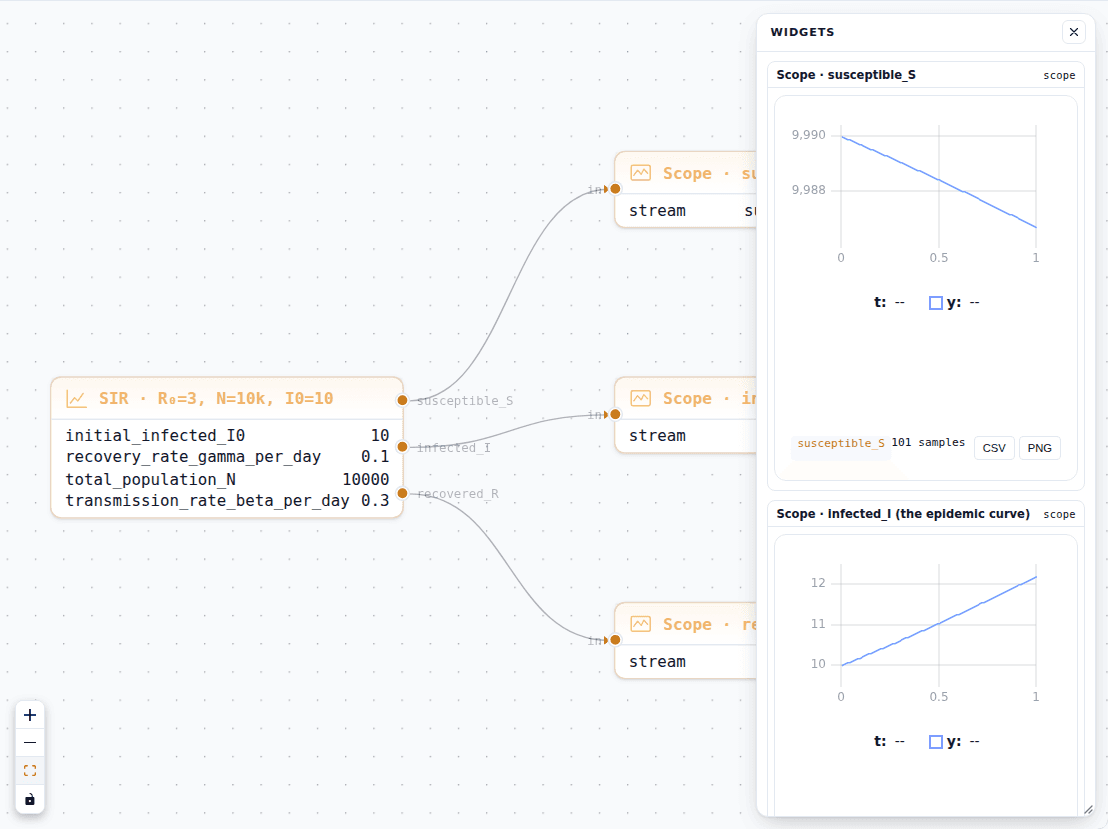
02 · Notebook & REPL
Edit any upstream cell and every dependent cell re-evaluates automatically — Pluto-style reactivity without the lock-in. A persistent WebSocket REPL lets you interrogate live state without re-running the whole notebook.
DjiniousLab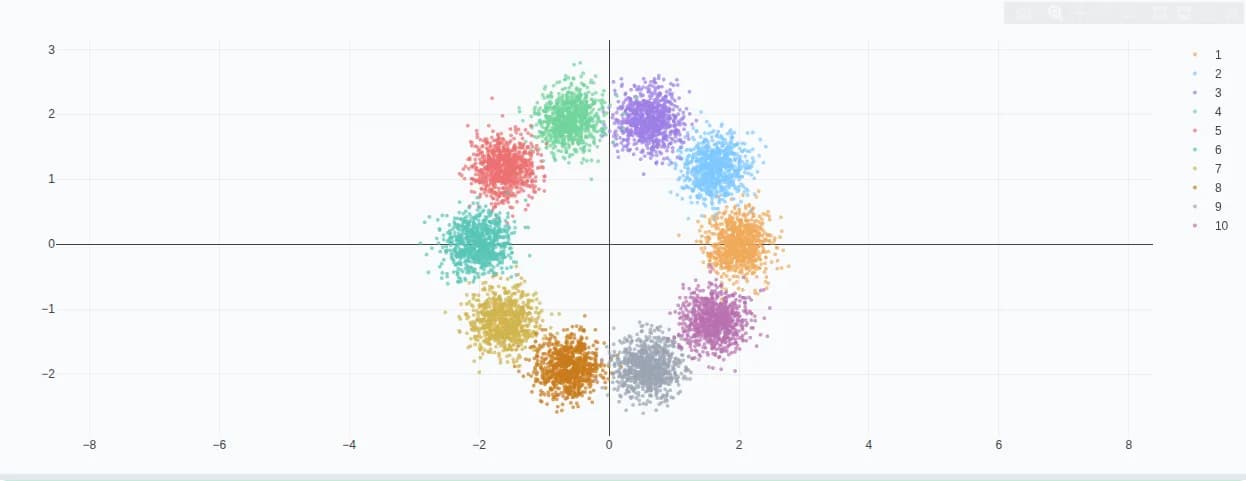
03 · Visualisation
Outputs stream into the notebook cell in real time: no waiting for a run to finish before you see the first plot tick — from a Plotly surface to a satellite swarm orbiting a Cesium globe.
DjiniousLab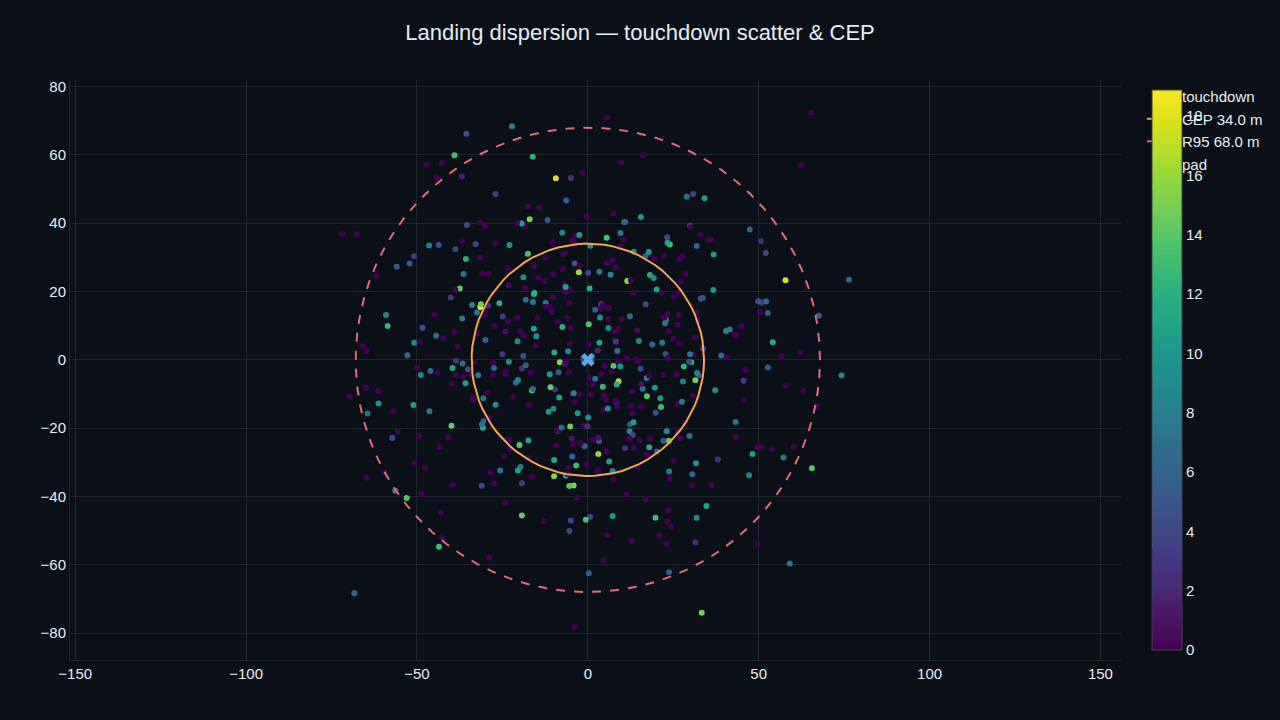
04 · Parametric CAD
Call show(part) and an interactive Three.js scene appears inline; call sweep_part(...) to generate STEP/STL variant families with a live progress bar. Generative design, where you hand the solver a load case and let it shape the part, is the direction we are building toward.
DjiniousLab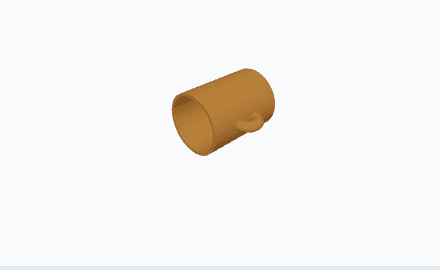
05 · Code generation
Compile any canvas model to deterministic, no_std Rust firmware via ModelingToolkit + StaticCompiler — the same symbolic pipeline that runs the solver drives the emitter. No hand-written wrappers, no bit-rot between sim and deployment.
DjiniousLab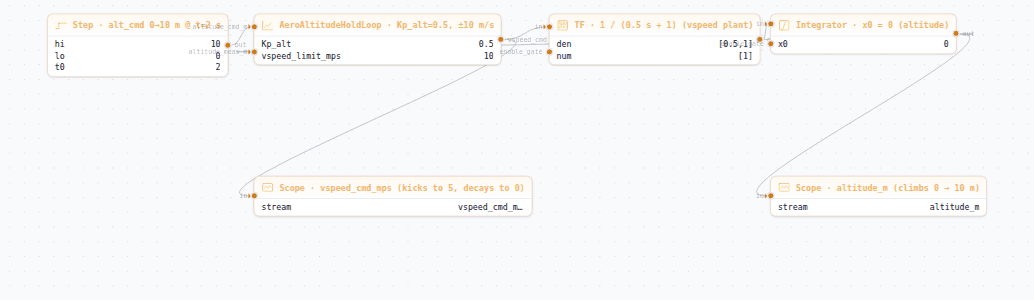
06 · Optimisation & RL
The Studies panel runs alongside the canvas, not in a separate tool. Every study emits live progress to the notebook, and trained policies export directly as blocks you can drop back into the model.
DjiniousLab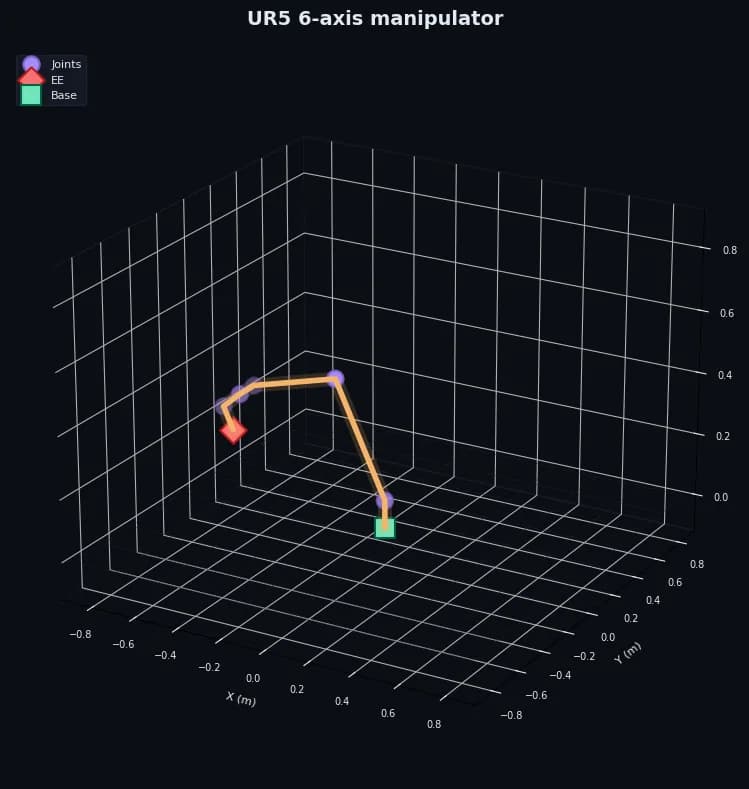
Library
DjiniousLab ships a deep library of pre-built canvases and notebooks across engineering and science domains — production-grade models, not toy examples. Every demo is a digital replica you can open and run on the same engine that powers production.
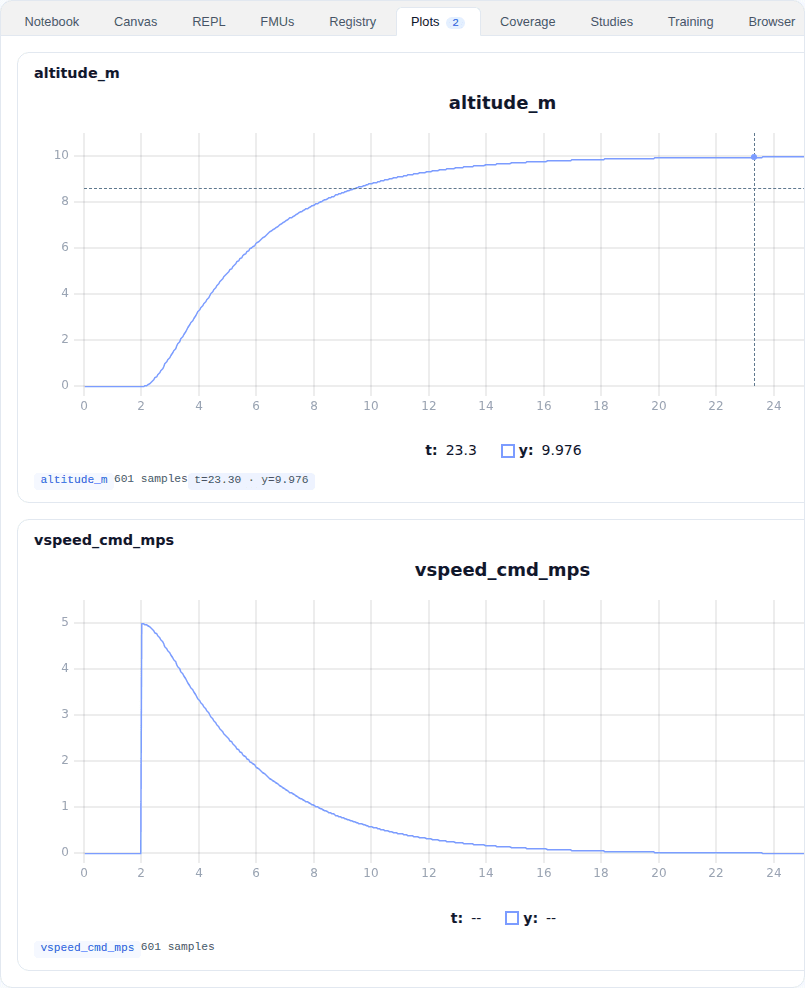
Closed-loop control and robotics — autopilots, motor drives, and manipulators modelled and tuned on the canvas.
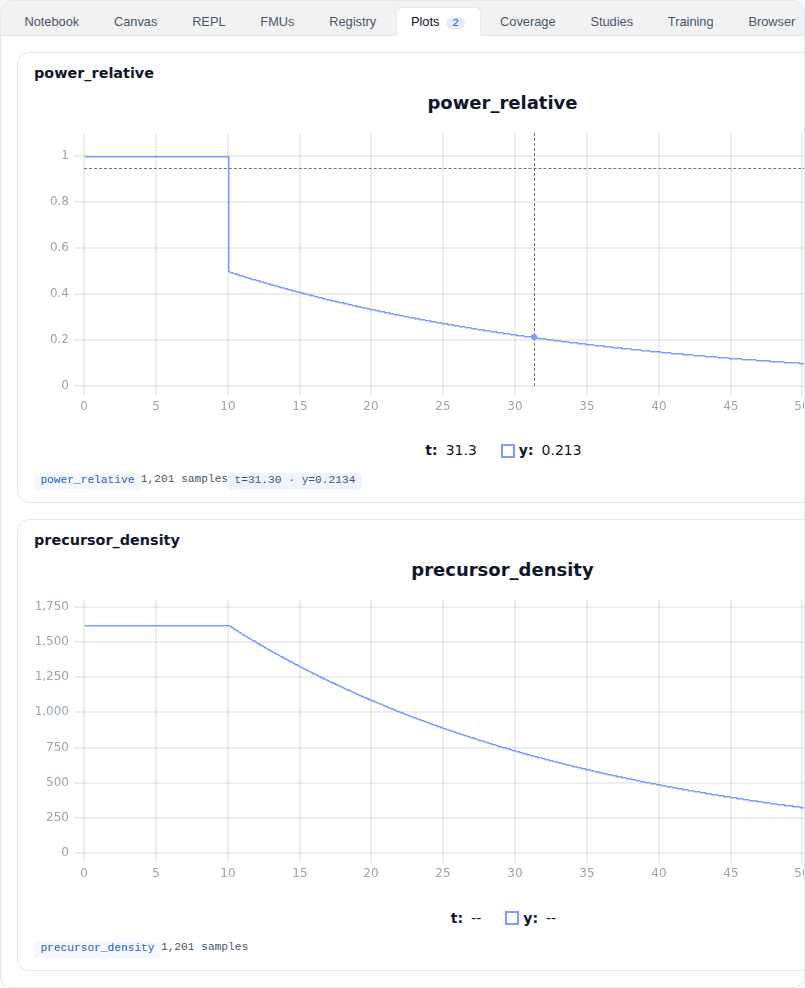
Reactors, separations, and water treatment — process dynamics and control from kinetics to compliance.
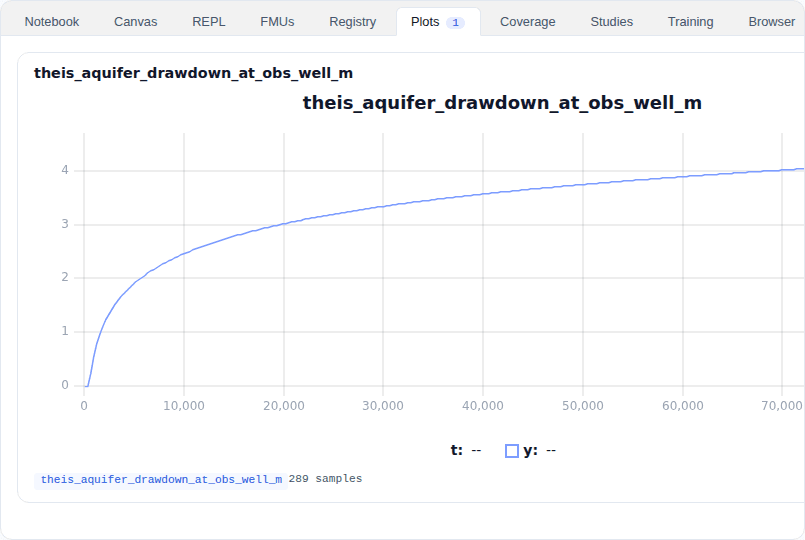
Earth systems — aquifers, climate feedbacks, ice sheets, and atmospheric chemistry.
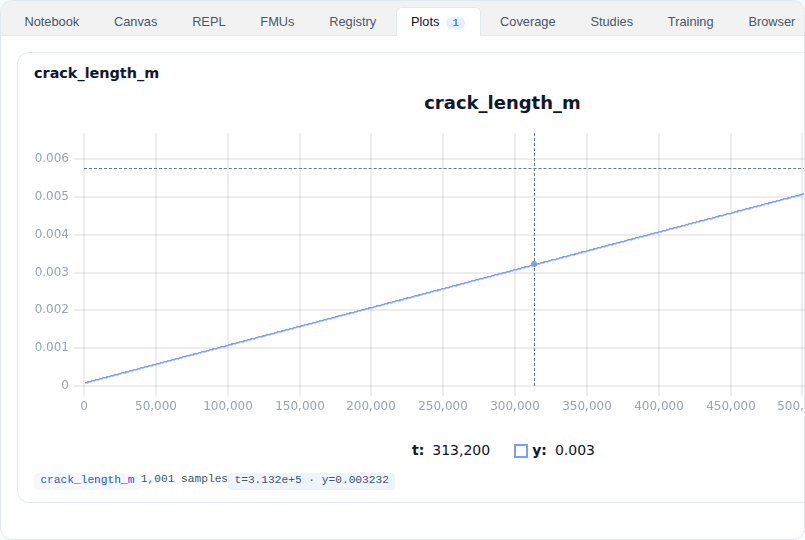
Materials and structural mechanics — phase transformations, fatigue, diffusion, and resonance.
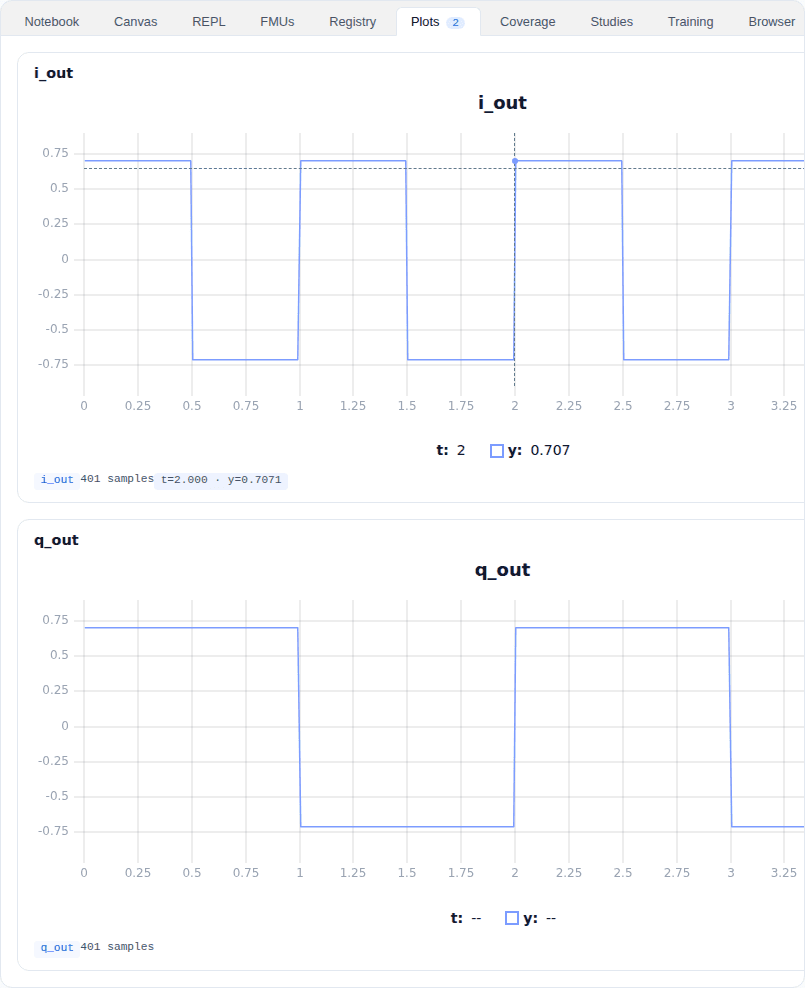
Signal processing and communications — modulation, carrier recovery, and adaptive filtering.
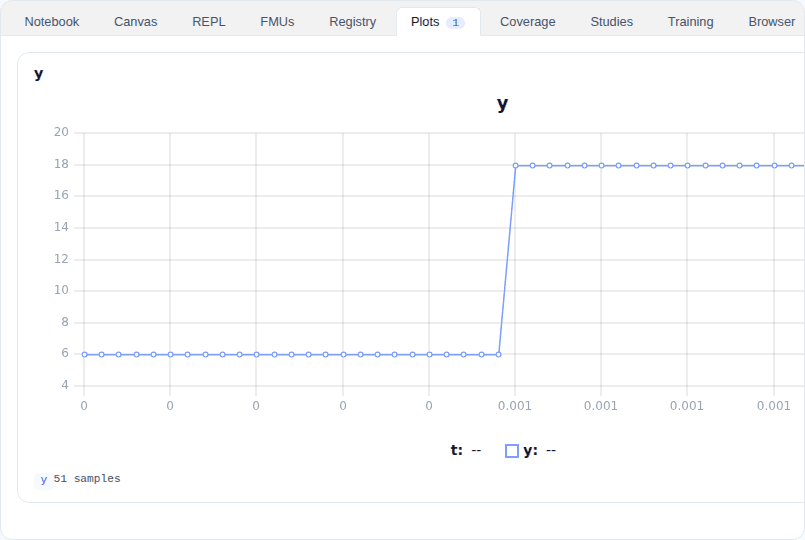
Power electronics and energy — converters, inverters, storage, and grid support.
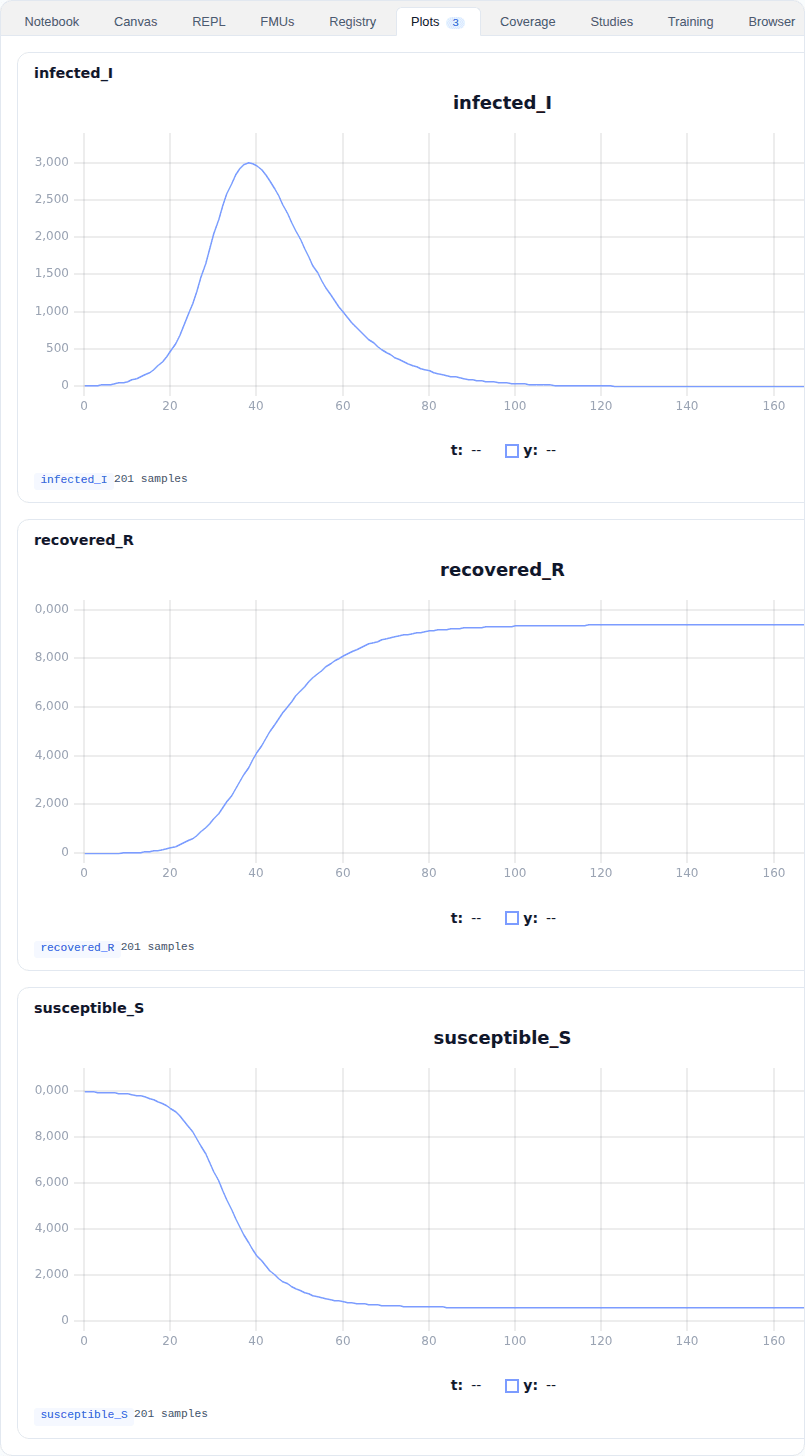
Physiology and epidemiology — cardiovascular dynamics, pharmacokinetics, neurons, and outbreak curves.
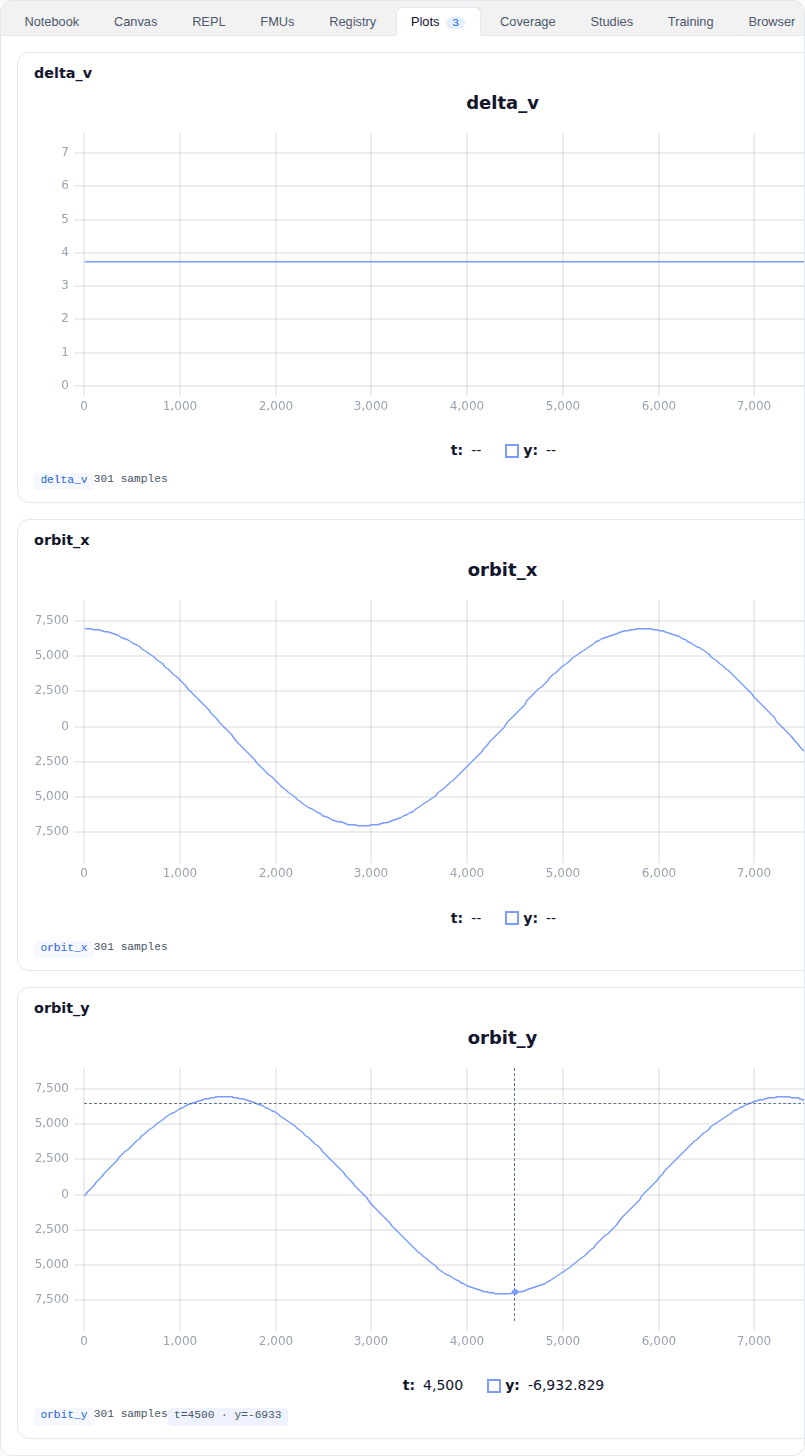
Aerospace, astrodynamics, and marine — orbital mechanics, vessel dynamics, and ocean mixing.
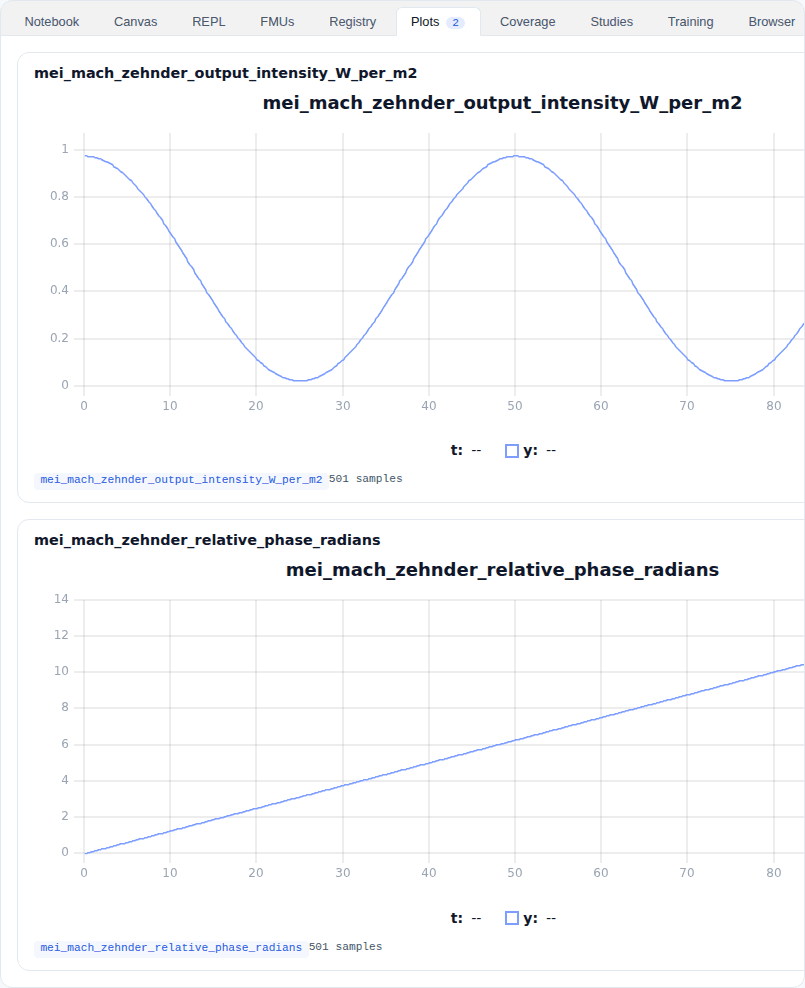
Optics and photonics — interference, polarization, and photon statistics.
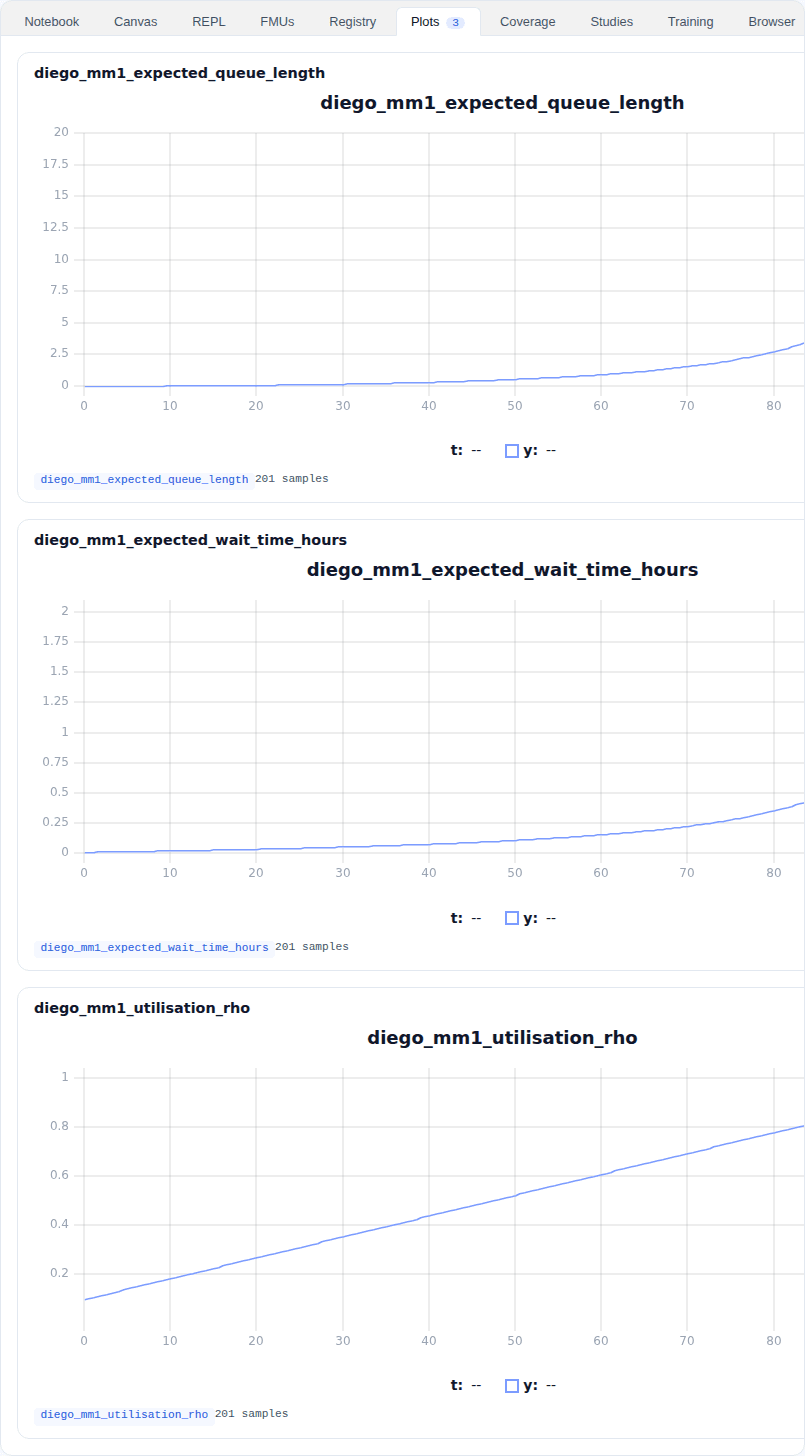
Operations and finance — queueing, inventory, forecasting, and option pricing.
Parametric 3-D / CAD with the3djin — programmatic geometry, parameter sweeps, and STEP export.
DjiniousLabAI & agents
DjiniousLab ships an in-app AI agent, two CLIs, and an MCP server — so you, your CI, and external agents like Claude Code, OpenAI Codex, and Pi can drive the whole model→simulate→generate loop programmatically, behind the same approval gates the UI uses.
A sidecar agent backed by your choice of LLM provider (keys encrypted at rest) with 30+ tools: it runs simulations, linearises models, fits symbolic laws, trains neural surrogates, and kicks off code generation.
DC-gain linearisation, symbolic regression, frequency-response and stability margins; MLP surrogate blocks, neural-ODE fits and auto-tuned PID and state-feedback controllers.
Every write operation and every REPL execution is gated: the assistant proposes the action and waits for an explicit confirmation before it runs. Read-only inspection never requires approval — only mutations do.
The djl binary mirrors the full SPA surface: projects, canvases (incl. node and edge editing), notebooks (incl. cell editing), and WebSocket-streamed runs, cell executions, and REPL sessions.
Any MCP-aware agent — Claude Code, OpenAI Codex, Cursor, Pi, OpenCode, or your own orchestrator — authenticates with a single revocable djmcp_ bearer token and calls the same toolset the in-app assistant uses.
A second CLI, djinious, handles the operator layer for deploy and CI: replay, codegen, sweep, optimise, rl-train, sign, verify and MATLAB transpilation.
DjiniousLab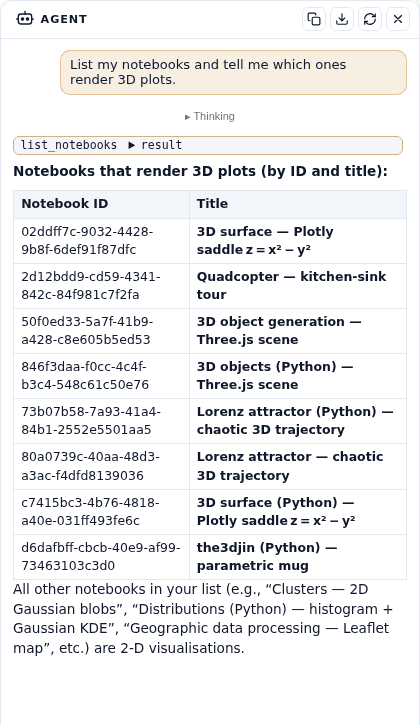
Capabilities
Every capability of DjiniousLab serves one loop: model your system as a digital replica, simulate and test it, then generate what ships. Integrated pillars, no toolbox unlocking, no per-seat add-ons.
Signal, electrical, mechanical, rotational, hydraulic, thermal, pneumatic and DSP blocks, plus domain libraries from robotics and aerospace to grid and power plant.
Algebraic-loop detection and Pantelides index reduction at compile time; GIR lowered to ModelingToolkit.jl with symbolic simplification.
Subsystem hierarchy, variant management, and per-node parameter override in one place.
Revolve, extrude, loft, offset, fillet, chamfer and boolean ops in plain Python; ParameterSet with bounds, units and expressions.
Tsit5 (explicit), Rodas5P (stiff), IDA (DAE) — chosen per-subsystem automatically.
Streaming scopes via Apache Arrow at >1 M samples/s with zero client-side buffering.
Julia and Python kernels, Pluto-style reactivity, and a REPL sharing the kernel process.
Plotly, Three.js, Cesium globe, Leaflet maps, sanitised SVG, inline canvas, parameter widgets and progress bars — lazy-loaded and streamed as the run proceeds.
Latin Hypercube, CMA-ES, Nelder-Mead, Bayesian GP.
Cartesian sweeps over all combinations with live progress ticks per iteration.
PPO, DDPG, SAC trained against the simulation environment; policies export as an FMU or a native block.
#![no_std] Rust — auditable, no_alloc, ready for IEC 61508 review — for STM32, Cortex-M, ESP32/RISC-V, WASM and x86-64.
CI verifies the firmware matches the simulation trace, deterministic regardless of OS or hardware.
the3djin emits STEP / STL geometry straight from a notebook cell today; generative design from simulated load cases is on the roadmap.
Wrap any compliant .fmu as a first-class canvas block; compile any DjiniousLab model for co-simulation in third-party tools.
Rate transitions, bus creator/selector, From/Goto — and MATLAB model import to ease migration from an existing block-diagram codebase.
Yjs CRDT: simultaneous canvas edits with presence cursors, zero merge conflicts.
Every save creates a commit; branch, diff, and revert from the UI. The GIR hash on every run links any result back to the exact model state that created it.
Trust
Run the digital replica of your product on your own infrastructure. Single sign-on, isolation, auditability, and observability are part of the platform, not an afterthought — deploy on-premises, in your cloud, or air-gapped with no changes to the architecture.
Bearer-JWT authentication with JWKS discovery. RS256 and ES256 only — alg:none is rejected at the gateway. Works out of the box with Okta, Auth0, Keycloak, and Zitadel.
OIDCPer-tenant isolation with fine-grained quotas on projects, models, notebooks, runs, and concurrent sessions; per-session metering feeds your billing pipeline.
Each compute session runs in a sandboxed worker: read-only rootfs, no network by default, seccomp filter applied. Firecracker microVM and gVisor runtimes are supported deployment targets.
Append-only audit trail with content-hash and version on every mutation, streamed to object storage with object-lock immutability.
Distributed OpenTelemetry traces across the gateway, workers, and frontend SPA, with SLO targets for cell round-trip, simulation start, and scope latency.
OTLPSCIM user and group provisioning path for RBAC per project — no manual account creation, no stale access.
SCIMMetadata and blobs stay in the region you choose. Hourly snapshots, plus GIR-hash run provenance enables bit-exact replay of any past simulation from scratch.
FMI 3.0 units, plain git repositories and human-readable Rust firmware that compiles without the platform. Air-gapped deployments run the full stack from a single compose file with no external dependencies.
STRIDE threat model, TLS enforced end-to-end, SBOM per artifact, signed run attestations, pinned toolchains, Trivy + cargo-audit scanning and Semgrep SAST.
In the digital thread
DjiniousLab does its part of the engineering loop and passes its evidence along — and it works just as well on its own.
DjiniousLabModelling & simulationOn its own, DjiniousLab is a complete model-based design environment: canvas, notebook, simulation, optimisation and code generation in one tool, with FMI 3.0 import and export to work alongside the tools you already use.
Use cases
34 worked cases.
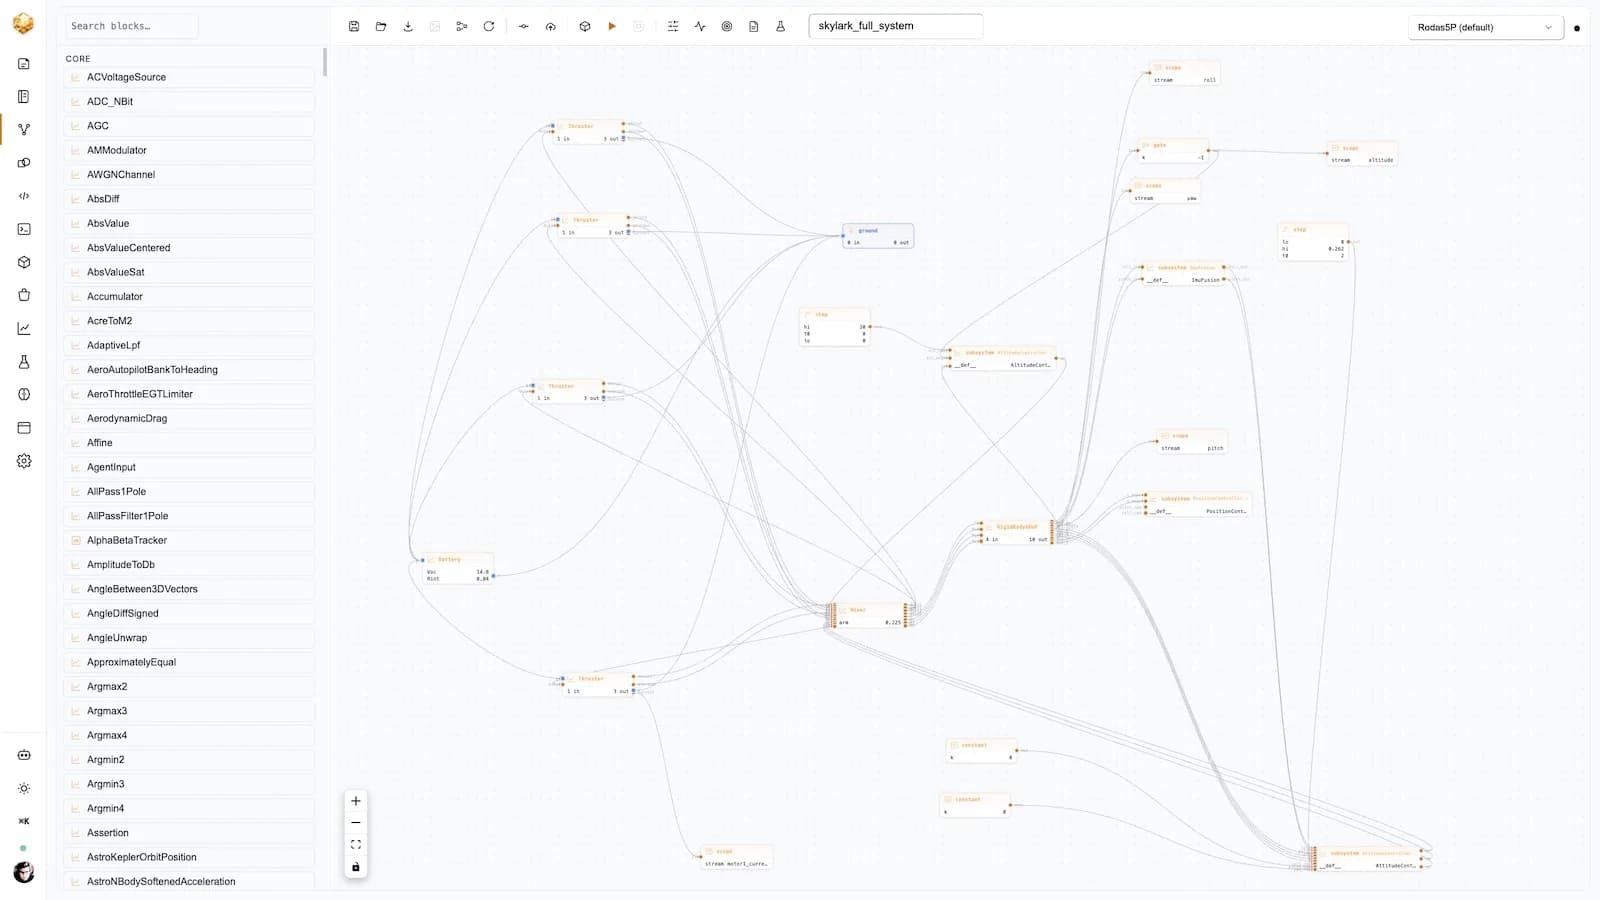 Aerial roboticsDjinborn T4 quadcopterA 450-class survey drone as one multibody composition — airframe, propulsion, sensors, and a cascaded autopilot flying a closed-loop 6-DoF mission.DjiniousLab
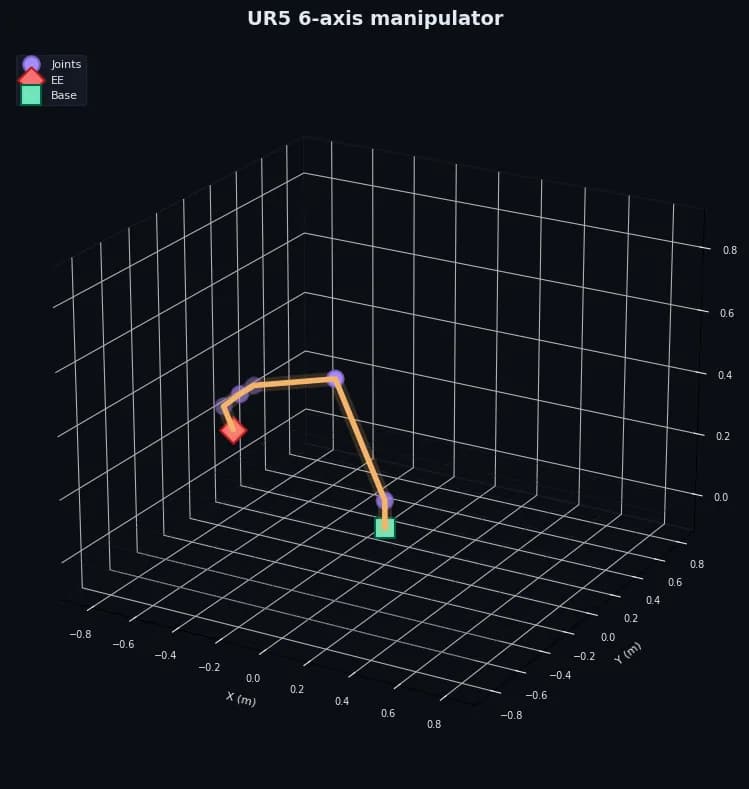 Industrial roboticsUR5 6-axis manipulatorA spatial 6-DoF UR5 arm as one multibody model — closed-form inverse kinematics driving a Cartesian end-effector path through per-joint PD control with gravity feedforward.DjiniousLab
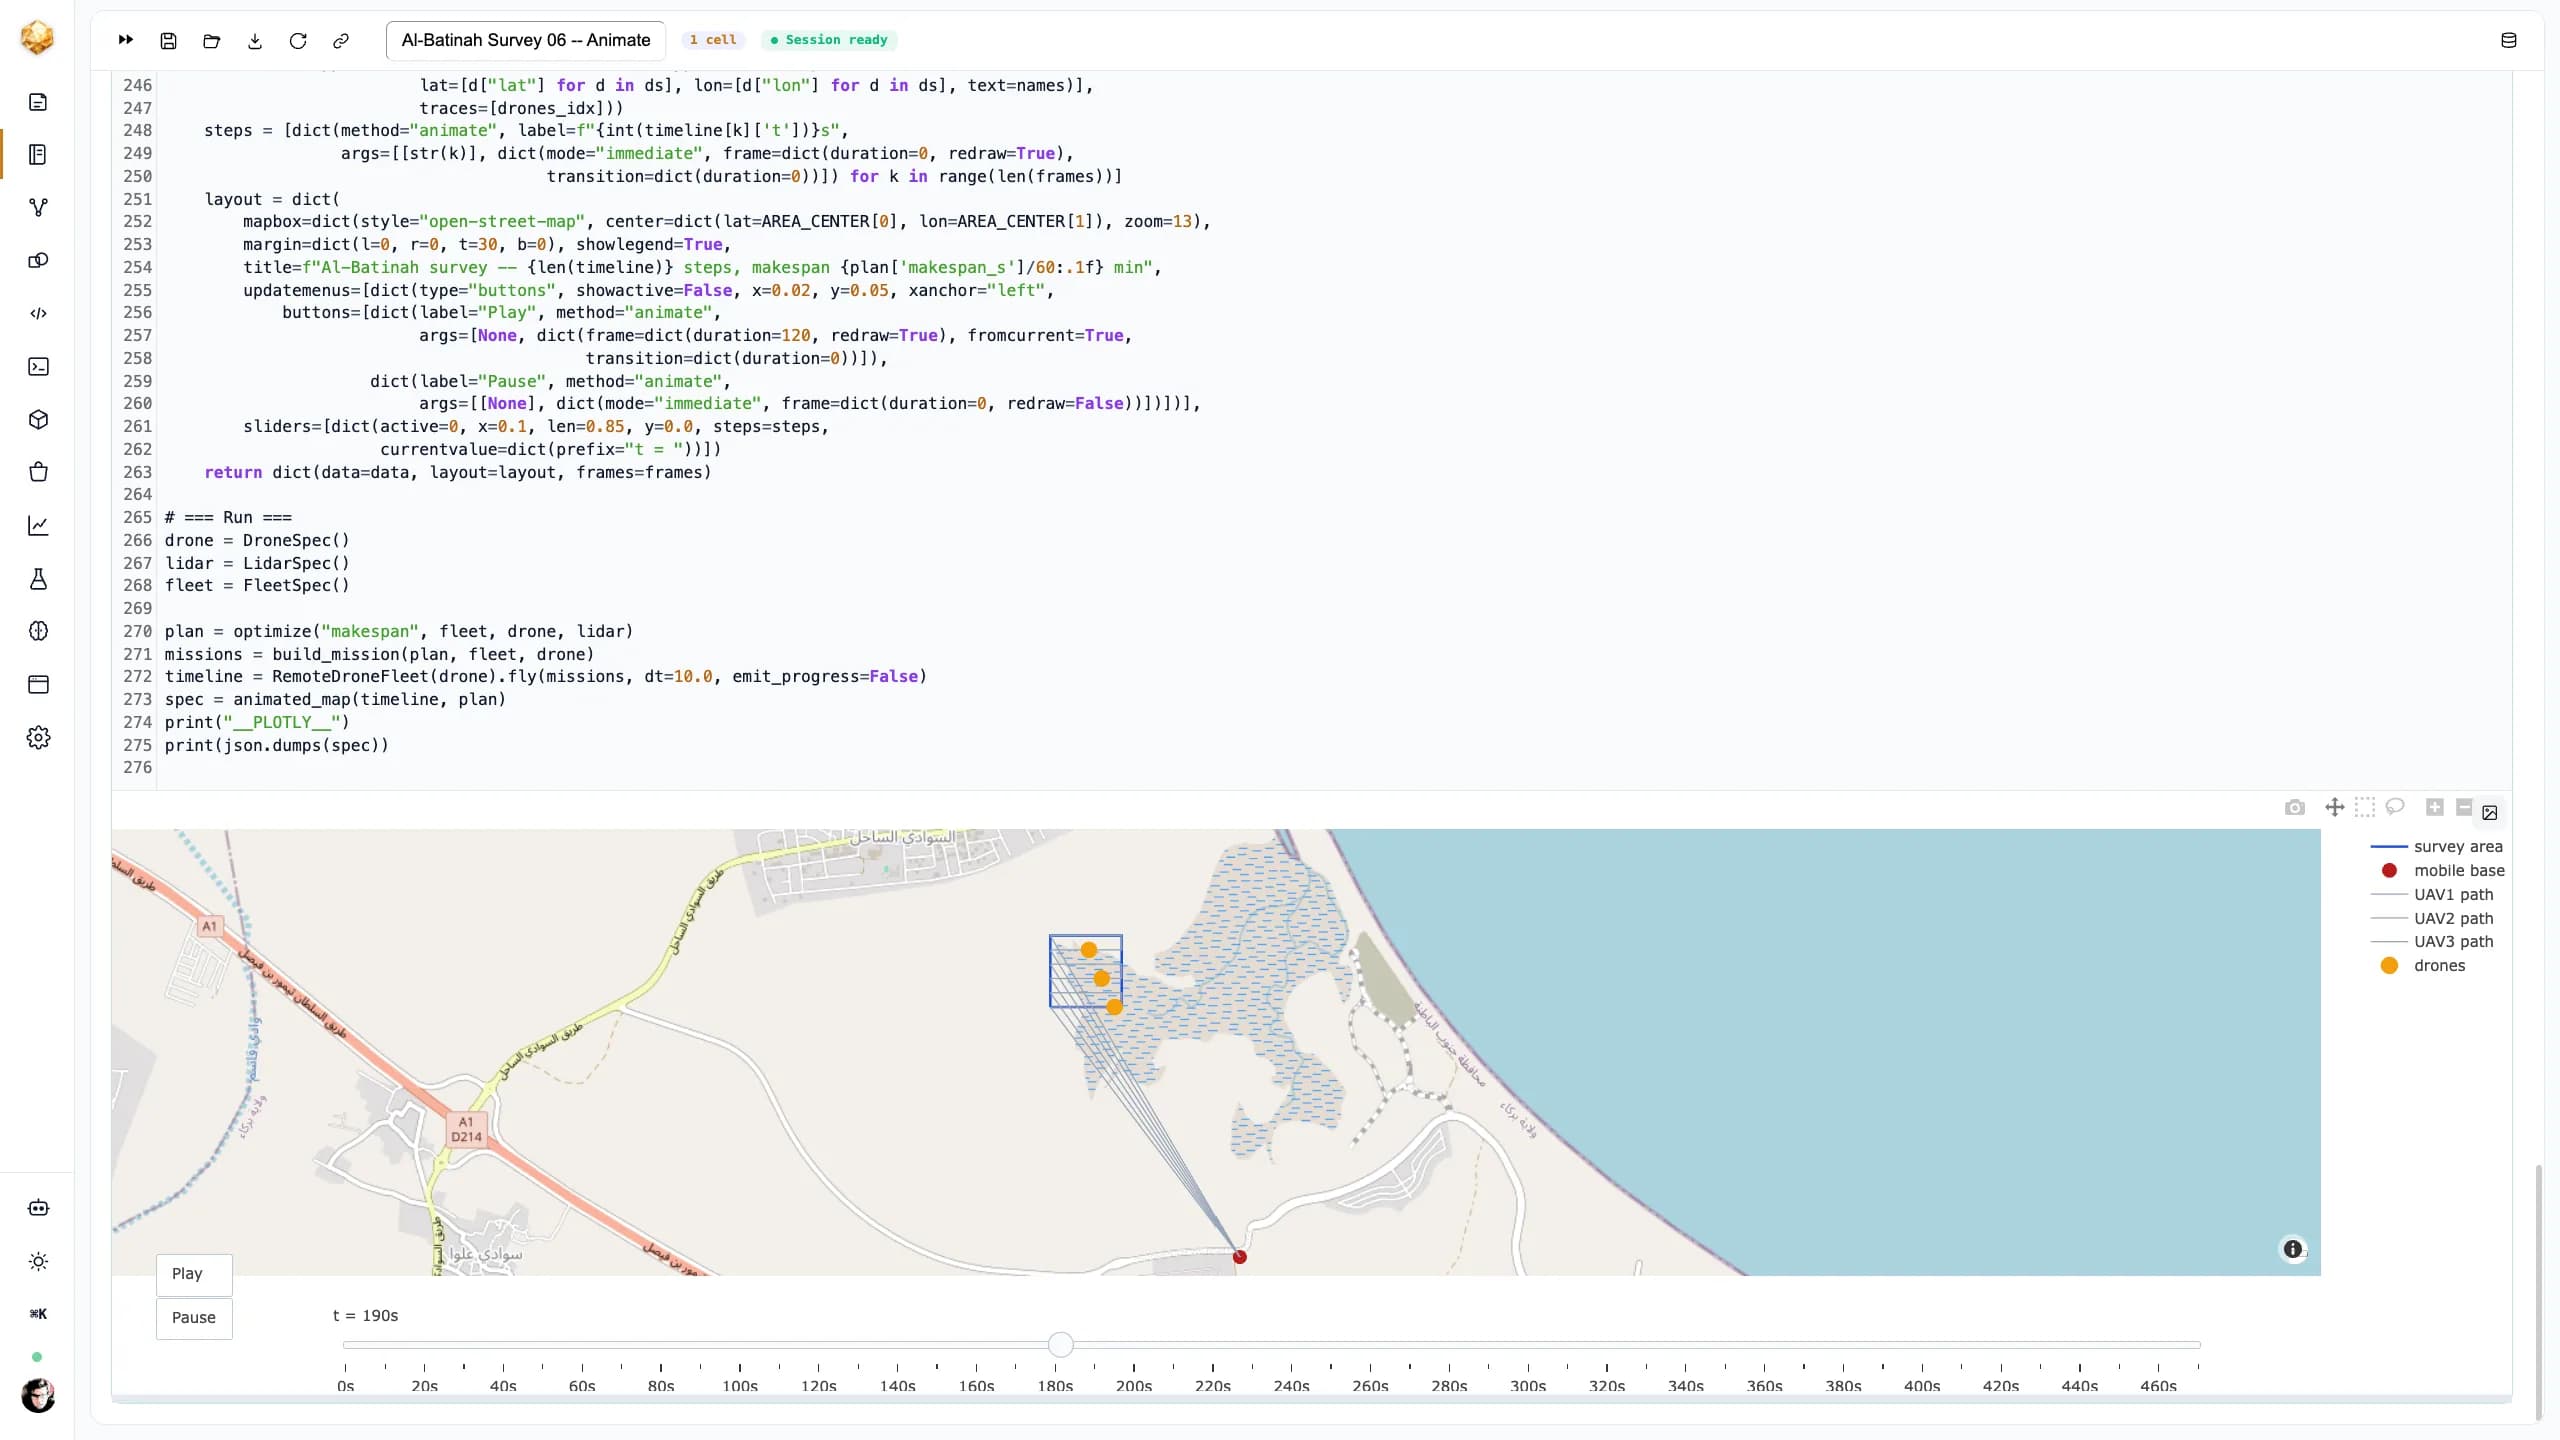 UAV surveyAl-Batinah UAV LiDAR surveyPlan and optimise a LiDAR drone-fleet survey of a 500 × 500 m site in Oman — tune the mission to your fleet, drone and sensor specs, then drive an optimal mission against a simulated UAV fleet on an animated map.DjiniousLab
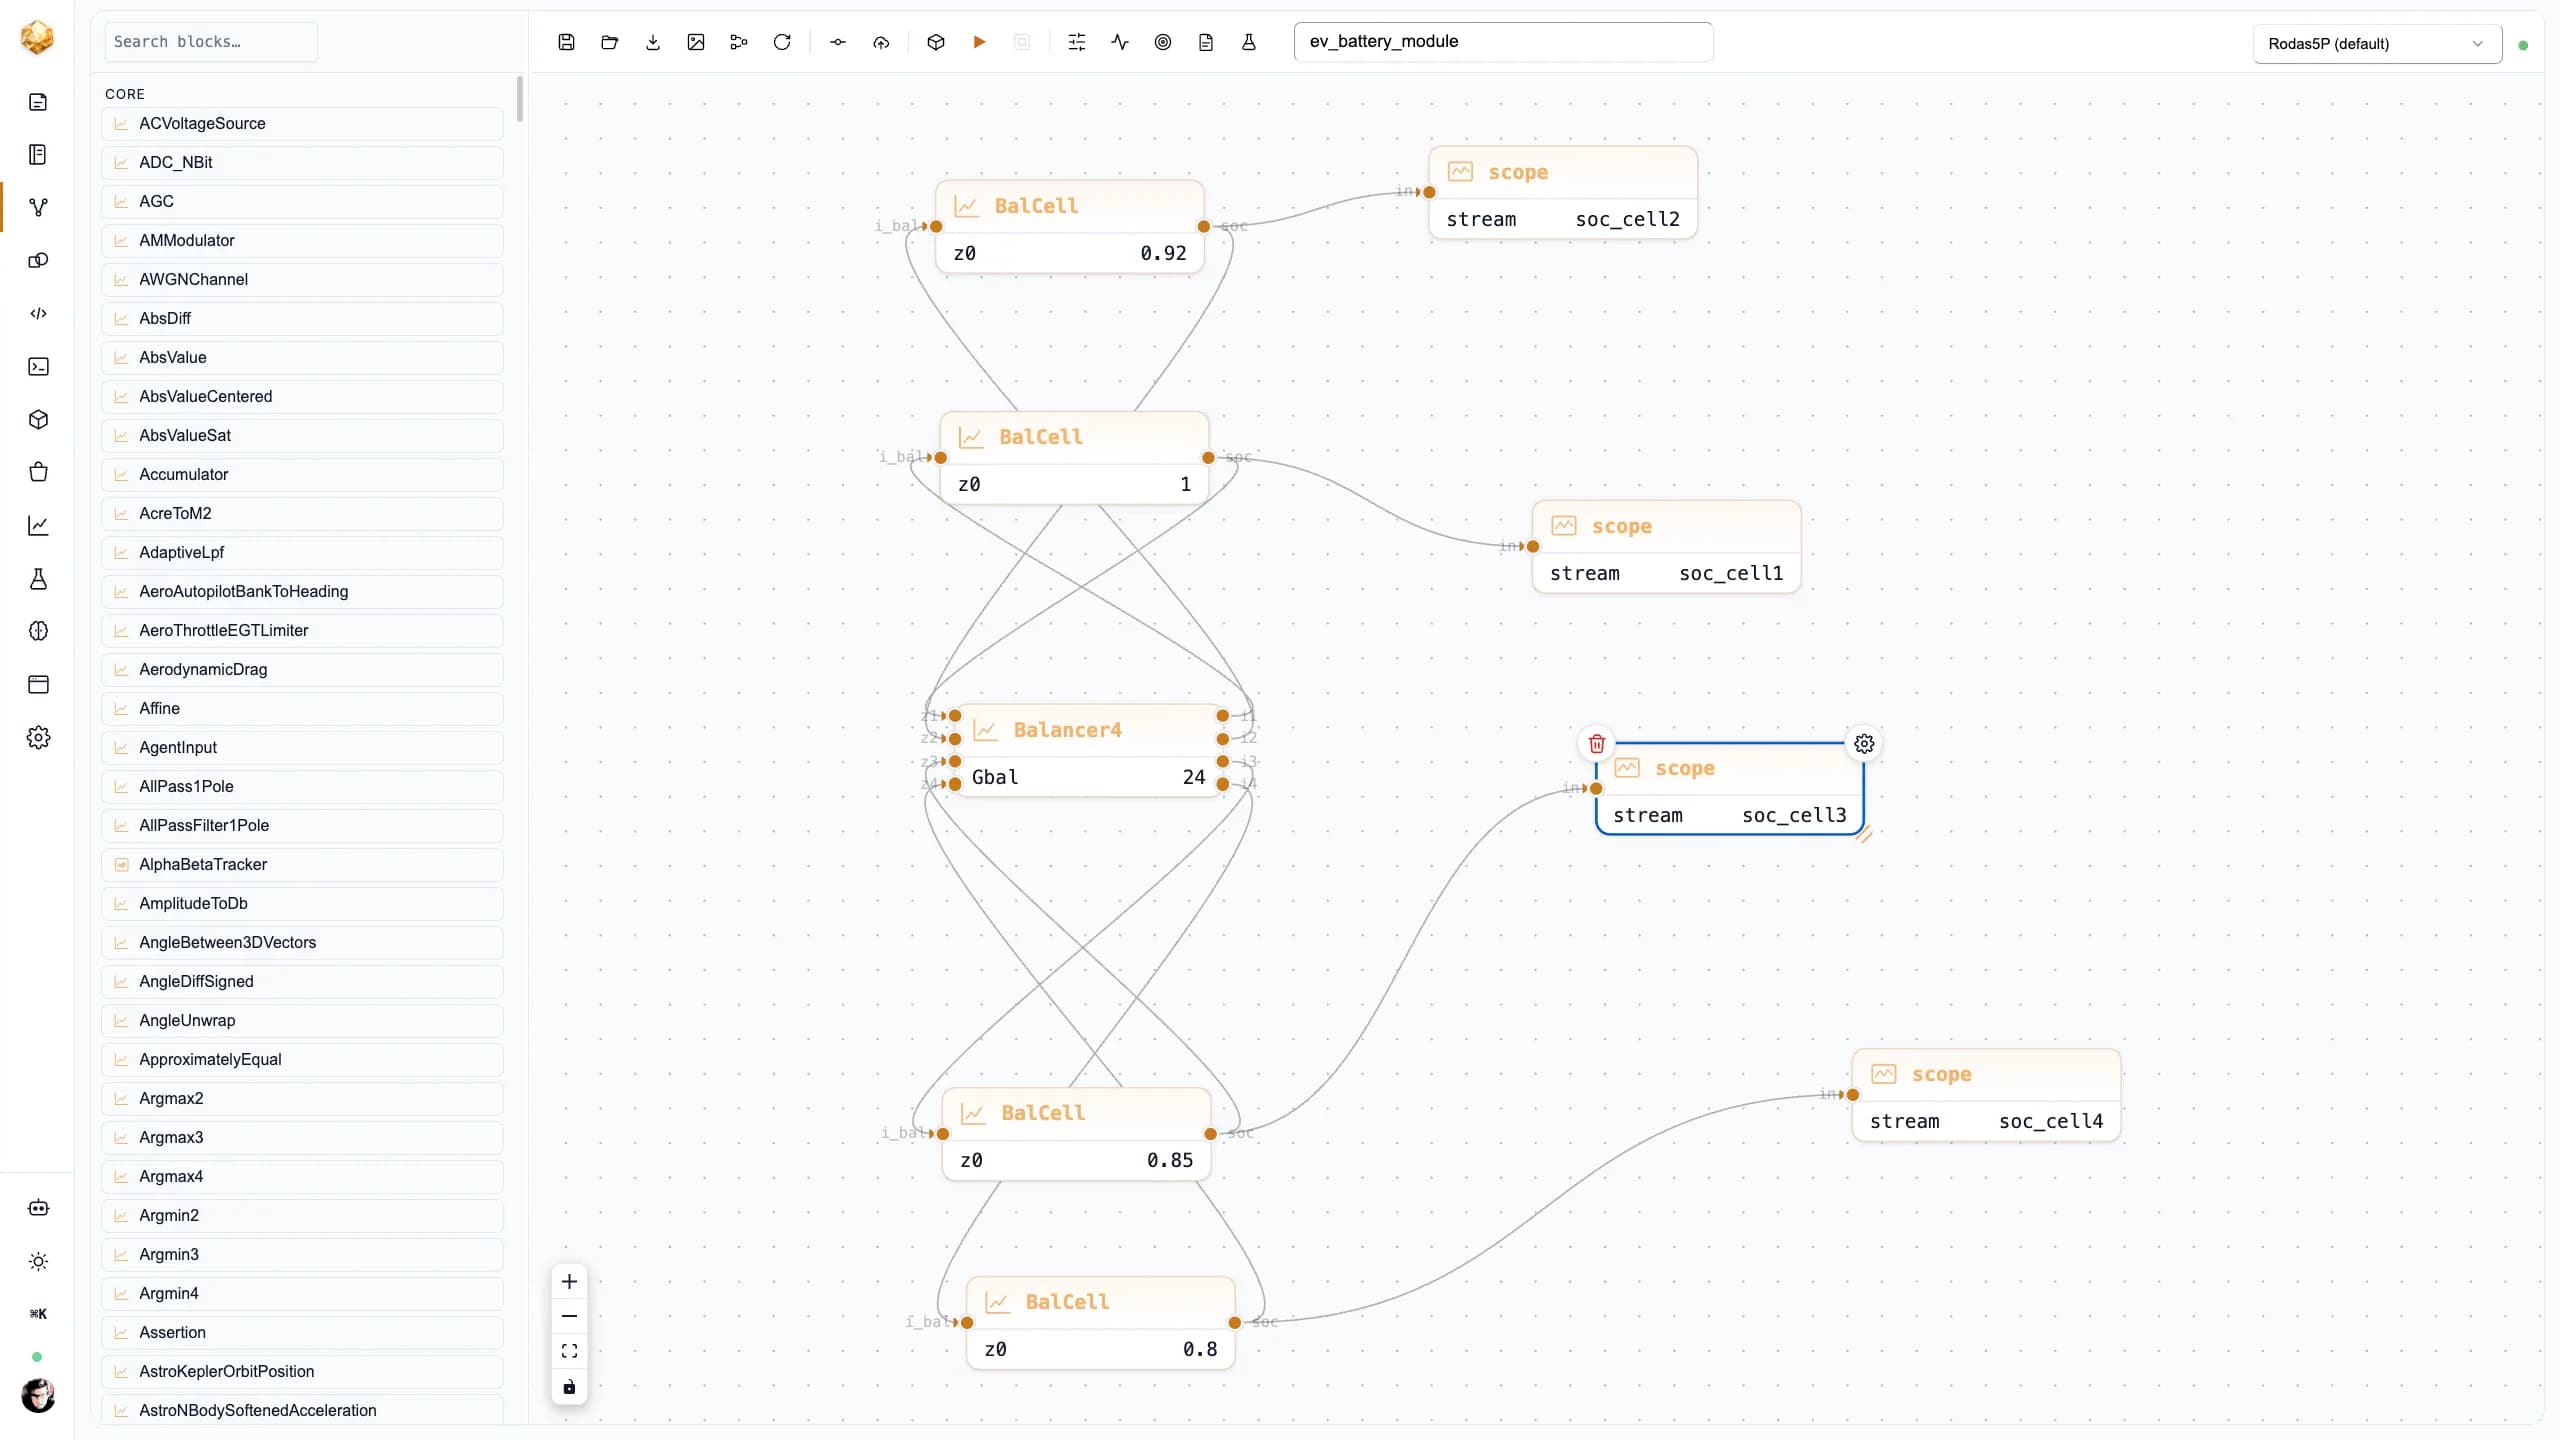 Battery systemsEV battery packAn electric-vehicle battery pack as one multi-domain model — equivalent-circuit cells, a coupled thermal network, a CC-CV charge controller and an active balancer, composed cell → module → pack and run end to end.DjiniousLab
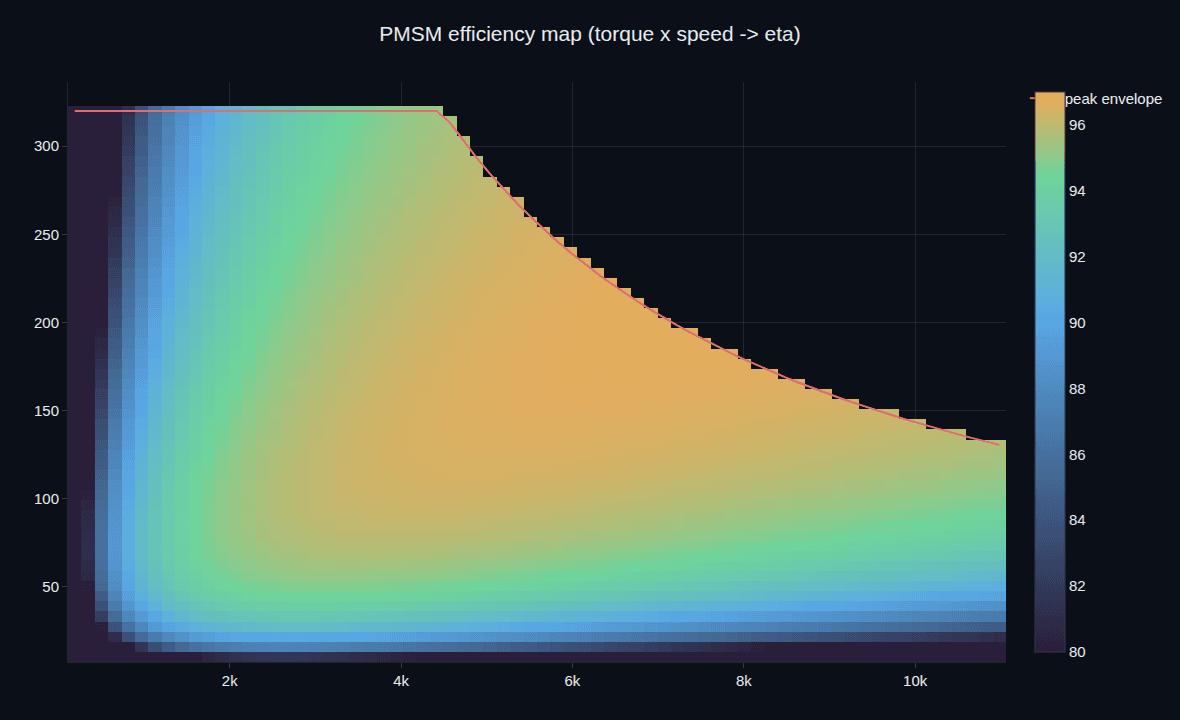 Electric vehiclesFull EV vehicleThe battery pack you sized becomes the car you drive — a complete electric vehicle over the WLTP cycle: drive cycle, traction motor, regen, the battery over the cycle, thermal, and the numbers that sell a car — range, consumption, and 0–100.DjiniousLab
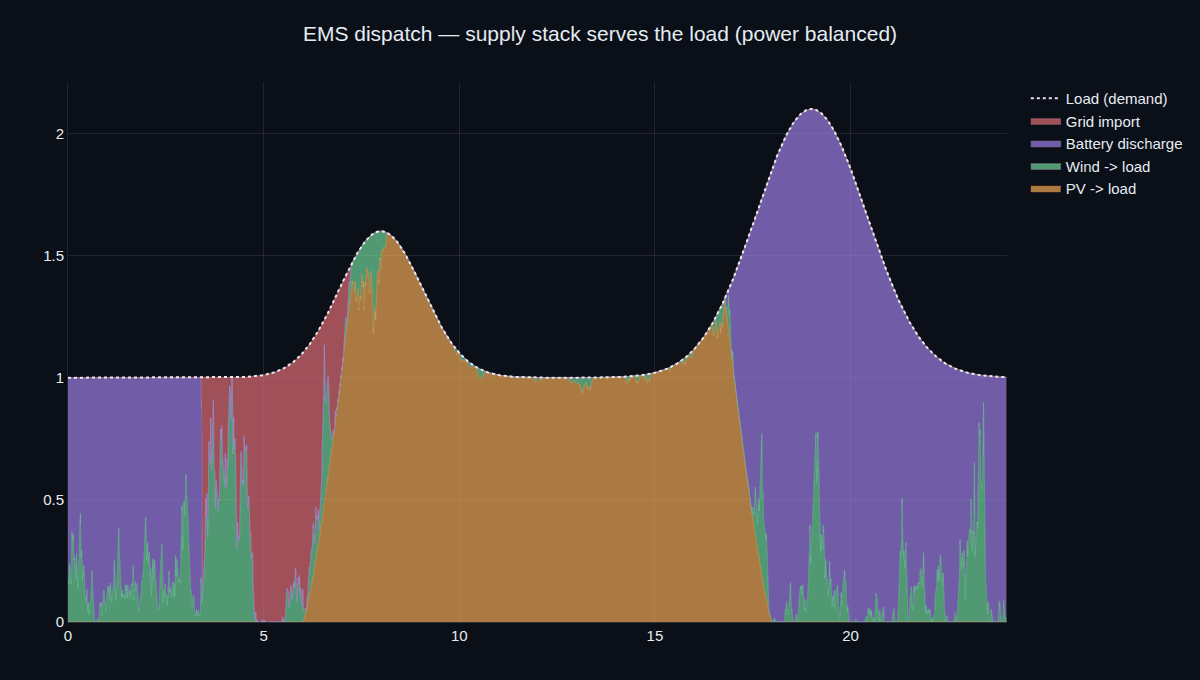 MicrogridsMicrogridSolar PV + wind + battery + grid-tie serving a load as one system under an energy-management controller — composed on a DC bus and run over a day: dispatch, self-sufficiency, peak-shaving, sizing, and islanded stability.DjiniousLab
Book a demo
See DjiniousLab on your models. We’ll walk your team through the workflows that matter to you — canvas, notebook, code-gen, or all three.
Along the thread
 DjiniousEngineeringOrchestration
The AI systems engineer: it takes the assignment and carries the whole project through a traceable System Ledger.
 DjiniousWorkshopSystem integration
Components wired into a complete system and closed through GPU physics in NVIDIA Isaac Sim.
 DjiniousSafeCertifiable code
Lean 4 specifications and kernel-checked proofs turned into panic-free embedded Rust, up to SIL 4.
 DjiniousWorkflowAgent automation
Graph automation any stage can call on: build a process, run it, watch it and audit it.